Skip to content

Operating-environment risk identification for dangerous goods transport vehicles based on unsafe driving behaviors

Sep 2026 · Figshare
Traffic and Road Safety

Abstract

Operating environments, including road infrastructure, traffic flow, weather conditions, and mileage, directly influence driving behavior. Because driving behavior ultimately determines road traffic safety, it is critical to determine whether operating environments create conditions that may induce unsafe driving practices. However, the relationship between operating environments and driving behavior is random, dynamic, and complex. These characteristics make it challenging to identify operating environment risks that are specific to driving behavior. To this end, this study develops a model to identify operating environment risks for road vehicles that transport dangerous goods. This study uses multi-modal data collected from in-vehicle terminals and integrates road, traffic, and weather information from MapInfo software, map APIs, and online weather pages to construct a dataset of vehicle operating environments. It then incorporates an enhanced attention mechanism to develop an explainable feature interaction graph neural network (AFi-GNN) that identifies operating environment risks. The proposed model outperforms the baseline models, achieving an AUC of 0.9682, an accuracy of 0.8724and a F1-score of 0.8892. The attention and SHAP results indicate that road- and traffic-related variables played important roles in model discrimination. Traffic-density level, nearby vehicle count, road type, speed, and driving distance were identified as important operating-environment indicators, while their relative importance and contribution directions differed across unsafe driving behavior categories. The results suggest that operating-environment risk identification for dangerous goods transport vehicles should be understood from the perspective of multi-factor interaction patterns rather than from a single indicator alone. The proposed AFi-GNN provides an interpretable modeling framework for identifying behavior-specific operating-environment risk patterns and may support high-risk scenario screening and active safety management for dangerous goods transport vehicles.
View source

Similar papers

#computer vision Conference Aug 2008

Scrum in a Multiproject Environment: An Ethnographically-Inspired Case Study on the Adoption Challenges

Agile methods continue to gain popularity. In particular, the Scrum method appears to be on the verge of becoming a de-facto standard in the industry, leading the so called Agile movement. While there are success stories and recommendations, there is little scientifically valid evidence of the challenges in the adoptio...

A. Marchenko, P. Abrahamsson · 59 citations · ⚡11
#computer vision Open access Sep 2012

Making the leap to a software platform strategy: Issues and challenges

A comprehensive taxonomy of the challenges faced when a medium-scale organization decided to adopt software platforms is provided, namely: business challenges, organizational challenges, technical challenges, and people challenges.

Yaser Ghanam, F. Maurer, P. Abrahamsson · 41 citations · ⚡3
#machine learning Open access Mar 2024

Integration of molecular coarse-grained model into geometric representation learning framework for protein-protein complex property prediction

MCGLPPI, a novel geometric representation learning framework that combines graph neural networks (GNNs) with the MARTINI molecular coarse-grained (CG) model to predict overall PPI properties accurately and efficiently, offers an effective and efficient solution for PPI overall property predictions.

Yang Yue, Shu Li, Yihua Cheng et al. · 15 citations

PepPCBench is a Comprehensive Benchmarking Framework for Protein-Peptide Complex Structure Prediction

PepPCBench enables a robust evaluation of PFNN-based methods and supports their continued development for peptide-protein structure prediction, and highlights the influence of peptide length, conformational flexibility, and training set similarity on prediction accuracy.

Si-Long Zhai, Huifeng Zhao, Ji-Ke Wang et al. · 13 citations · ⚡1
#machine learning Open access Sep 2025

Unified and explainable molecular representation learning for imperfectly annotated data from the hypergraph view

OmniMol is presented, a framework using hypergraphs to improve predictions of molecular properties, addressing challenges of imperfect data annotation and enhancing model explainability, and achieves state-of-the-art performance in properties prediction.

Bowen Wang, Junyou Li, Donghao Zhou et al. · 11 citations

Related blog posts

Microsoft Research Blog Jul 13, 2026

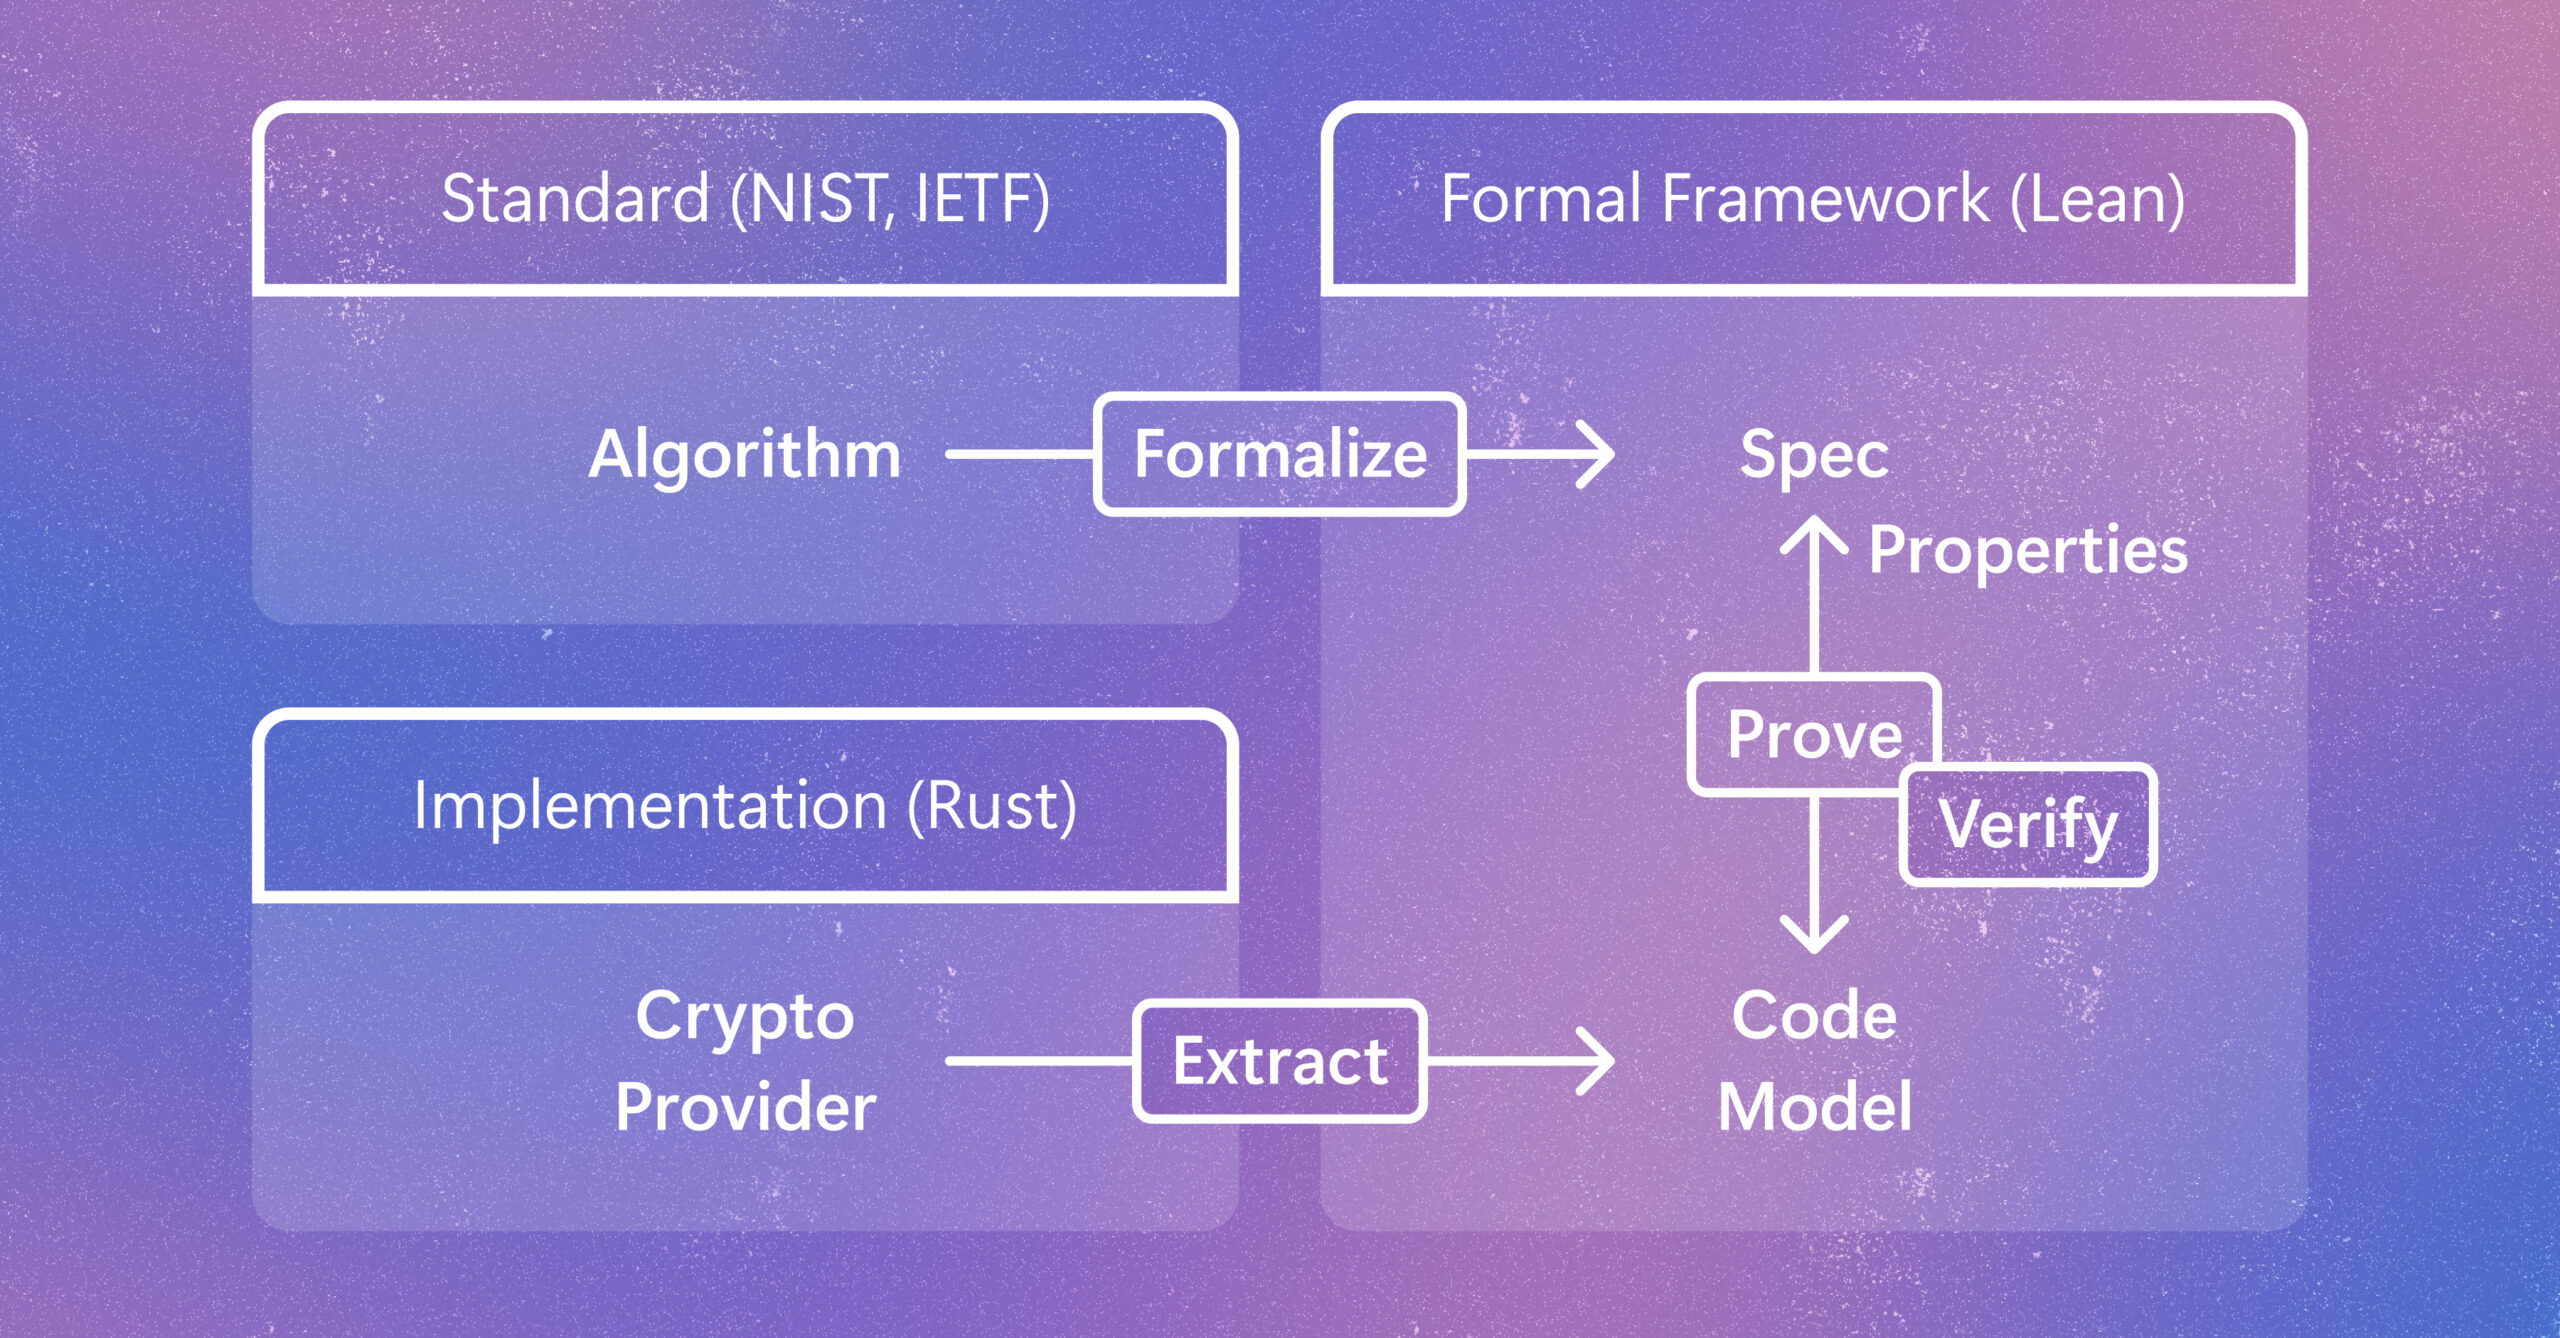
Verifying Rust cryptography in SymCrypt, from standards to code

Cryptographic code supports vital protections in modern computing systems. Learn how a new method helps verify code as developers write it while preserving speed and adaptability as it gets implemented and evolves. The post Verifying Rust cryptography in SymCrypt, from standards to code appeared first on Microsoft Research.

We use cookies to run the site and, with your consent, for analytics and to show ads. See our Cookie Policy.