Simulation is a powerful tool for robotics, but building diverse, simulation-ready scenes at scale remains difficult. Reconstructing scenes from single images is a promising alternative, but visual similarity alone is insufficient: objects must also be recovered, accurately placed, and physically grounded. Existing methods that rely on post-hoc physics settling often misplace objects, producing scenes that look correct but behave poorly under manipulation. We present SceneRig, an agentic system that turns a single image into an editable, simulation-ready scene. SceneRig combines geometric, visual, and physical tools to reconstruct a faithful 3D scene. An agent then performs edit-and-validate loops inside a physics simulator to achieve physical stability. Across diverse inputs, SceneRig improves instance segmentation, object-centric appearance, and 3D placement while keeping the reconstructed scenes physically stable. Furthermore, SceneRig is effective for downstream robotics: its scenes predict real-robot policy outcomes more accurately than the baseline method and more reliably support replay of recorded manipulations without trajectory adaptation.
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
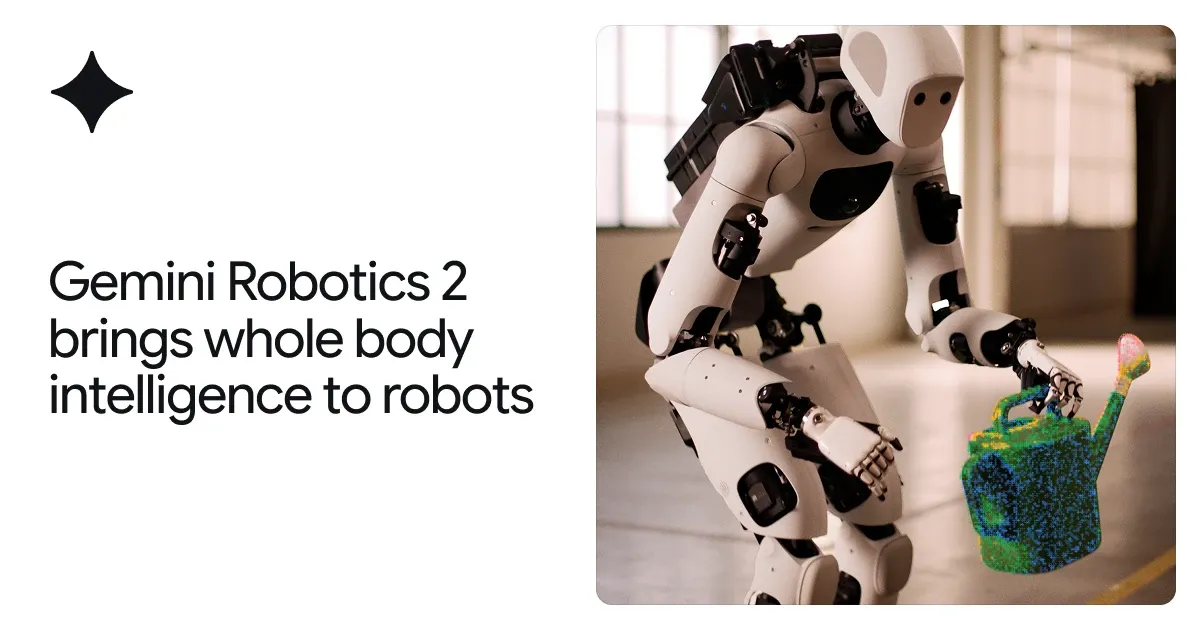
From feet to fingertips — we are teaching robots intelligent whole-body control, fine dexterity, and teamwork to complete a broad range of complex tasks.
Known for his clear and elegant writing style, Bertsekas shaped fields from control and optimization to large-scale computation and artificial intelligence.
We use cookies to run the site and, with your consent, for analytics and to show ads.
See our Cookie Policy.