Integrated CAN-Bus System: A Software-Defined Multi-Threaded Instrument Cluster and Open Observability Telemetry Architecture for Vehicle Performance Optimization
The results prove the platform provides a highly flexible, extensible, and economically accessible open-source alternative to proprietary motorsport instrumentation.
Abstract
The adoption of standalone Engine Control Units (ECUs) in motorsport and research vehicles introduces severe interoperability challenges with OEM electronic architectures, often rendering factory instrument clusters inoperative. Existing commercial displays address this but feature high costs, closed ecosystems, and limited extensibility. This paper presents a low-cost, software-defined automotive instrument cluster and telemetry platform built on a Raspberry Pi 4, bridging heterogeneous vehicle subsystems without modifying ECU firmware. The architecture unifies high-rate CAN bus acquisition, analog digitization, discrete chassis signal monitoring, and GNSS telemetry. To evaluate network expansion, an auxiliary Exhaust Gas Temperature (EGT) loop using a MAX31855 amplifier was integrated to broadcast thermal data over CAN to a Link G4+ ECU. A priority-scheduled multi-threaded software model ensures bounded application-level acquisition alongside graphical visualization and an onboard time-series database (TSDB) with an embedded Grafana observability framework. Experimental validation on a cross-manufacturer testbed (Mazda RX-8 with a Nissan SR20DET engine and Link G4+ ECU) demonstrated stable operation during long-duration testing. Stress-testing up to 1000 frames/s with no frame loss was observed. The results prove the platform provides a highly flexible, extensible, and economically accessible open-source alternative to proprietary motorsport instrumentation.
A safety-oriented architectural framework that constrains how AI-enabled functions may be integrated into fail-operational by-wire systems and clarifies trade-offs among safety isolation, latency, and AI performance while preserving braking safety guarantees under continuous software evolution is proposed.
Soumyasudharsan Srinivasaraghavan· SAE technical paper series· 0 citations
A four-layer framework that supports traceable, bidirectional interaction between a system’s architecture and its physical implementation and contributes to MBSE-driven digital twin research by providing a structured process for integrating architecture, translation, execution, monitoring, and synchronization in a trac...
M. Islam, Aditya Akundi, Sergio A. Luna Fong· Systems· 0 citations
Onboard satellite intelligence requires a task layer that translates mission intent into local tool calls, exposes execution state, and returns machine-consumable artifacts under communication and power constraints. We present SAT-Edge-Agent, a hardware-in-the-loop (HIL) edge-agent system deployed on a commercial off-t...
Modern AI and HPC systems integrate accelerators, high-speed networks, and management controllers at rack scale. Developing software for this infrastructure typically requires access to scarce, costly hardware, while software abstractions can obscure how workloads depend on resources across servers and accelerators. Th...
W. Janjua, Eoin O'Connell, Mihai Penica· 0 citations
This paper presents the design and implementation of the On-Board Software (OBSW) for a 1.5U educational CubeSat nanosatellite based on an IMA (Integrated Modular Avionics) architecture. The system runs on the XtratuM XNG real-time hypervisor on a Zybo Z7 (Zynq-7000) platform, ensuring temporal and spatial isolation be...
Lucía Alba, A. Nieto, L. Ortiz et al.· Jornadas de Automática· 0 citations
The 10.4-m Gran Telescopio Canarias (GTC) began science operations in 2009 and is controlled by a distributed system based on CORBA/TAO, which complicates long-term maintenance and interoperability with modern subsystems and with new projects such as the EST and NRT. New telescope control systems increasingly rely on h...
J. A. Rodríguez Losada, Víctor Rodríguez Herreros, Fernando Merlos-García et al.· Astronomical Telescopes + In...· 1 citation
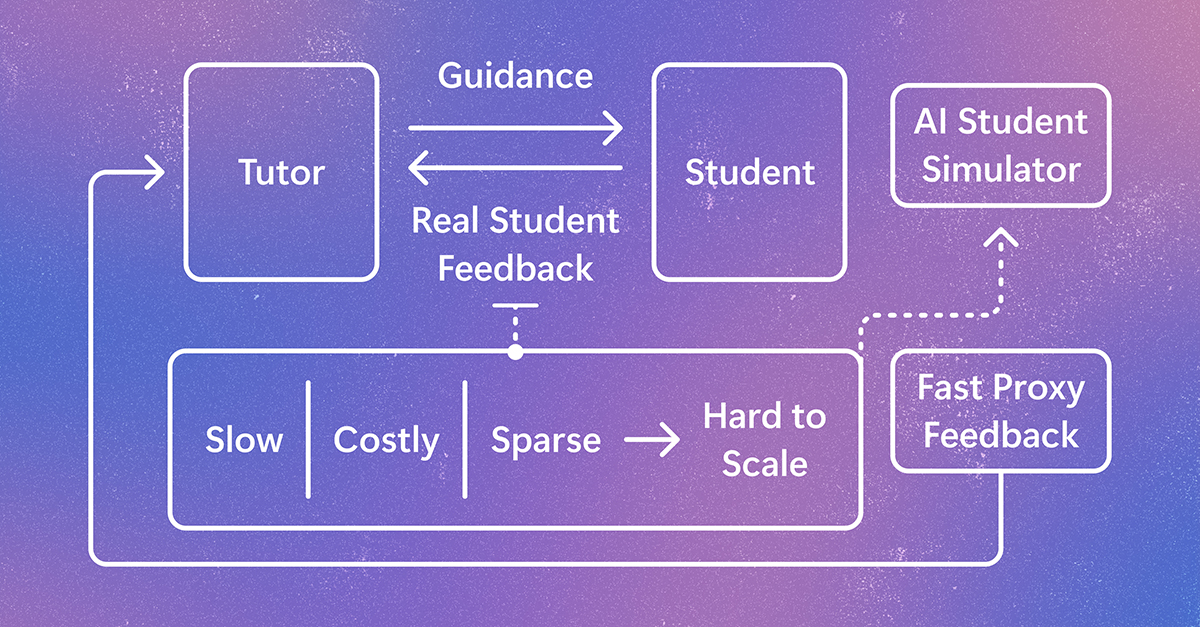
StudentSim is a research system for evaluating and improving AI tutoring tools before they are tested with learners. It models how individuals may engage with tutors, giving feedback to improve tutor performance across subjects like chess, writing, and mathematics. The post Simulating student learning for better AI tutoring appeared first on Microsoft Research.
MIT News · Artificial Intelligence· news.mit.eduOct 6, 2026
Writing as a participant and researcher, PhD student JS Tan SM ’22 has co-authored a new book about the rise of tech worker protests and the employer backlash that followed.
We use cookies to run the site and, with your consent, for analytics and to show ads.
See our Cookie Policy.