Skip to content
#software testing Open access

FROM HARVEST TO PACKAGE: AN AUTONOMOUS ROBOT FOR INTEGRATED TOMATO PICKING AND BAGGING

Aug 2026 · INMATEH Agricultural Engineering · 0 citations · 9 references

Abstract

In addressing the high labor costs and low operational efficiency of greenhouse tomato harvesting and separate packaging workflows, this study develops an integrated tomato harvesting robotic system embedded with RGB-D machine vision, 5-degree-of-freedom manipulator and vertical heat-sealing net bag packaging mechanism. The YOLOv8s lightweight detection model trained on self-built multi-light greenhouse tomato dataset (1260 annotated images covering unobstructed, semi-occluded and heavily occluded fruits) is adopted to identify ripe tomatoes with a recognition accuracy of 95.2%, and ImageJ software is introduced to conduct secondary maturity screening via RGB chromatographic analysis. A* global path planning combined with TEB local trajectory optimization realizes autonomous obstacle avoidance navigation of the wheeled mobile platform, while RRT-Connect bidirectional random tree algorithm is applied for obstacle-free grasping trajectory planning inside dense tomato canopies. A total of 120 valid cyclic tests are carried out in simulated greenhouse environment to verify the full-chain automation including fruit detection, in-situ picking and instant bagging. Experimental results show that the average single-fruit processing cycle is 12.1 s, with a picking success rate of 90.8% and bagging success rate of 98.3%. Compared with skilled manual picking and packaging, the overall working efficiency is improved by approximately 30%. This system firstly realizes continuous integrated harvesting and commercial packaging operation for greenhouse tomatoes, providing a feasible technical solution for full-process intelligent protected agriculture.
Read PDF

Similar papers

Open access Jul 2026

Design and Experimental Validation of a Vision-Based Robotic Framework for Strawberry Harvesting

The automation of fruit harvesting has become an important research topic in precision agriculture due to increasing labor shortages, rising production costs, and the need for improved harvesting efficiency. Among horticultural crops, strawberries present particular challenges for robotic harvesting because of their va...

David Campoamor, Julio Vega · 0 citations
Conference Aug 2026

Score-Based Harvesting Order Planning and False Detection Handling for Robotic Tomato Harvesting

Robotic tomato harvesting is crucial for addressing agricultural labor shortages. However, existing systems struggle with optimal order planning in dense clusters and erroneous motions caused by false detections. We propose a robotic harvesting system evaluated in a controlled setting with artificial tomatoes, making t...

M. Ishino, Takumi Yamamoto, Runqian Zhang et al. · 0 citations
2026

Vision-Guided Agricultural Robot for Crop Detection Using Edge Computing on Embedded Hardware

The experimental re-sults demonstrate the feasibility of deploying advanced computer vision models on embedded platforms for agricultural applications, enabling autonomous crop detection and harvesting assistance in controlled indoor conditions, representing a first step toward real-world field deployment.

Luis Prieto-López, Iván Pascual, Mencía George et al. · 0 citations
Review Open access Aug 2026

Height-Based Stratification in Greenhouse Harvesting Robotics: A Review from Ground-Level to High-Wire Crops

Labor shortages and the push for higher greenhouse efficiency have accelerated interest in automated harvesting. However, the development of a universal harvesting robot has been constrained by large variations in crop architecture, especially plant height. In this review, a height-based stratification of greenhouse ha...

Zu-Hui Zhou, Yi-Le Chen, Wenshuo Gao et al. · 0 citations
Open access 2026

AI-Driven Closed-Loop Agricultural Robotics for Precision Phenotyping and Autonomous Selective Harvesting

This study develops and field-evaluated AgriLoop-1, a unified robotic platform combining a multi-modal perception suite, a compliant end-effector for damage-aware fruit handling, and a co-designed AI software architecture that effectively closes the perception–action loop in agricultural robotics.

Seddiki Noureddine, Belghachi Mohamed · 0 citations
Jul 2026

STEMbot: A Compliant Robot for Under-Canopy Plant Navigation

The scalability of organic agriculture is partially limited by the labor costs associated with monitoring for pests. While drones and rovers are well-suited for agricultural monitoring from above or next to plants, many pests live on the underside of leaves or on plant stems, making them detectable only after they have...

Zachary S. Charlick, N. R. Choudhury, Haoyu Ma et al. · 0 citations

Related blog posts

Microsoft Research Blog Oct 12, 2026

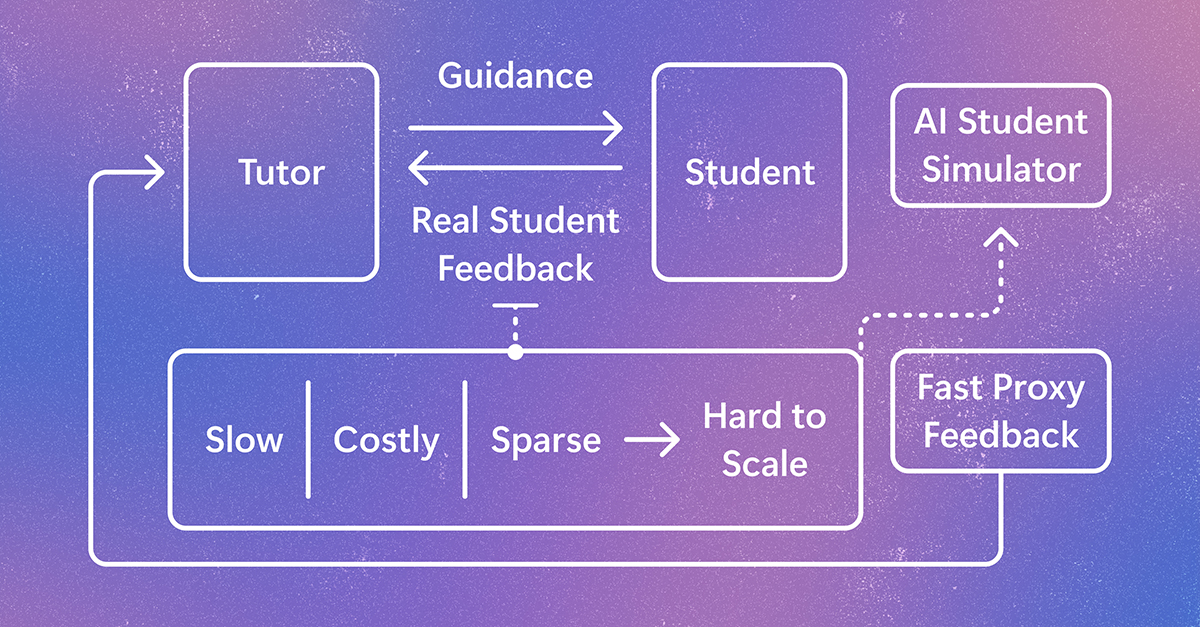
Simulating student learning for better AI tutoring

StudentSim is a research system for evaluating and improving AI tutoring tools before they are tested with learners. It models how individuals may engage with tutors, giving feedback to improve tutor performance across subjects like chess, writing, and mathematics. The post Simulating student learning for better AI tutoring appeared first on Microsoft Research.

MIT News · Artificial Intelligence Oct 2, 2026

Documenting the tech worker movement

Writing as a participant and researcher, PhD student JS Tan SM ’22 has co-authored a new book about the rise of tech worker protests and the employer backlash that followed.

We use cookies to run the site and, with your consent, for analytics and to show ads. See our Cookie Policy.