Skip to content

Generalizable Dense Reward for Long-Horizon Robotic Tasks

Mar 2026 · arXiv.org · Vol abs/2604.00055 · 3 citations · ⚡ 1 influential · 39 references
Computer Science

TL;DR

VLLR is proposed, a dense reward framework combining an extrinsic reward from Large Language Models (LLMs) and Vision-Language Models (VLMs) for task progress recognition, and an intrinsic reward based on policy self-certainty based on policy self-certainty for PPO finetuning.

Abstract

Existing robotic foundation policies are trained primarily via large-scale imitation learning. While such models demonstrate strong capabilities, they often struggle with long-horizon tasks due to distribution shift and error accumulation. While reinforcement learning (RL) can finetune these models, it cannot work well across diverse tasks without manual reward engineering. We propose VLLR, a dense reward framework combining (1) an extrinsic reward from Large Language Models (LLMs) and Vision-Language Models (VLMs) for task progress recognition, and (2) an intrinsic reward based on policy self-certainty. VLLR uses LLMs to decompose tasks into verifiable subtasks and then VLMs to estimate progress to initialize the value function for a brief warm-up phase, avoiding prohibitive inference cost during full training; and self-certainty provides per-step intrinsic guidance throughout PPO finetuning. Ablation studies reveal complementary benefits: VLM-based value initialization primarily improves task completion efficiency, while self-certainty primarily enhances success rates, particularly on out-of-distribution tasks. On the CHORES benchmark covering mobile manipulation and navigation, VLLR achieves up to 56% absolute success rate gains over the pretrained policy, up to 5% gains over state-of-the-art RL finetuning methods on in-distribution tasks, and up to $10\%$ gains on out-of-distribution tasks, all without manual reward engineering. Additional visualizations can be found in https://silongyong.github.io/vllr_project_page/


View source

Similar papers

#artificial intelligence Conference Open access Jun 2018

Gibson Env: Real-World Perception for Embodied Agents

This paper investigates developing real-world perception for active agents, proposes Gibson Environment for this purpose, and showcases a set of perceptual tasks learned therein.

F. Xia, Amir Zamir, Zhi-Yang He et al. · 1,069 citations · ⚡112
#computer vision Review Sep 2017

Agile Software Development Methods: Review and Analysis

This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.

P. Abrahamsson, O. Salo, Jussi Ronkainen et al. · 727 citations · ⚡54
#computer vision Jun 2008

The impact of agile practices on communication in software development

The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.

M. Pikkarainen, Jukka Haikara, O. Salo et al. · 401 citations · ⚡48
#machine learning Review Open access Oct 2014

Software development in startup companies: A systematic mapping study

The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.

Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al. · 394 citations · ⚡54

Diffusion models as plug-and-play priors

The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.

Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al. · 316 citations · ⚡15

Related blog posts

MIT News · Artificial Intelligence Oct 28, 2026

Making machines that can listen

Professor Paris Smaragdis develops computers with superhuman hearing for applications like speech recognition, music understanding, and environmental monitoring.

Microsoft Research Blog Aug 11, 2026

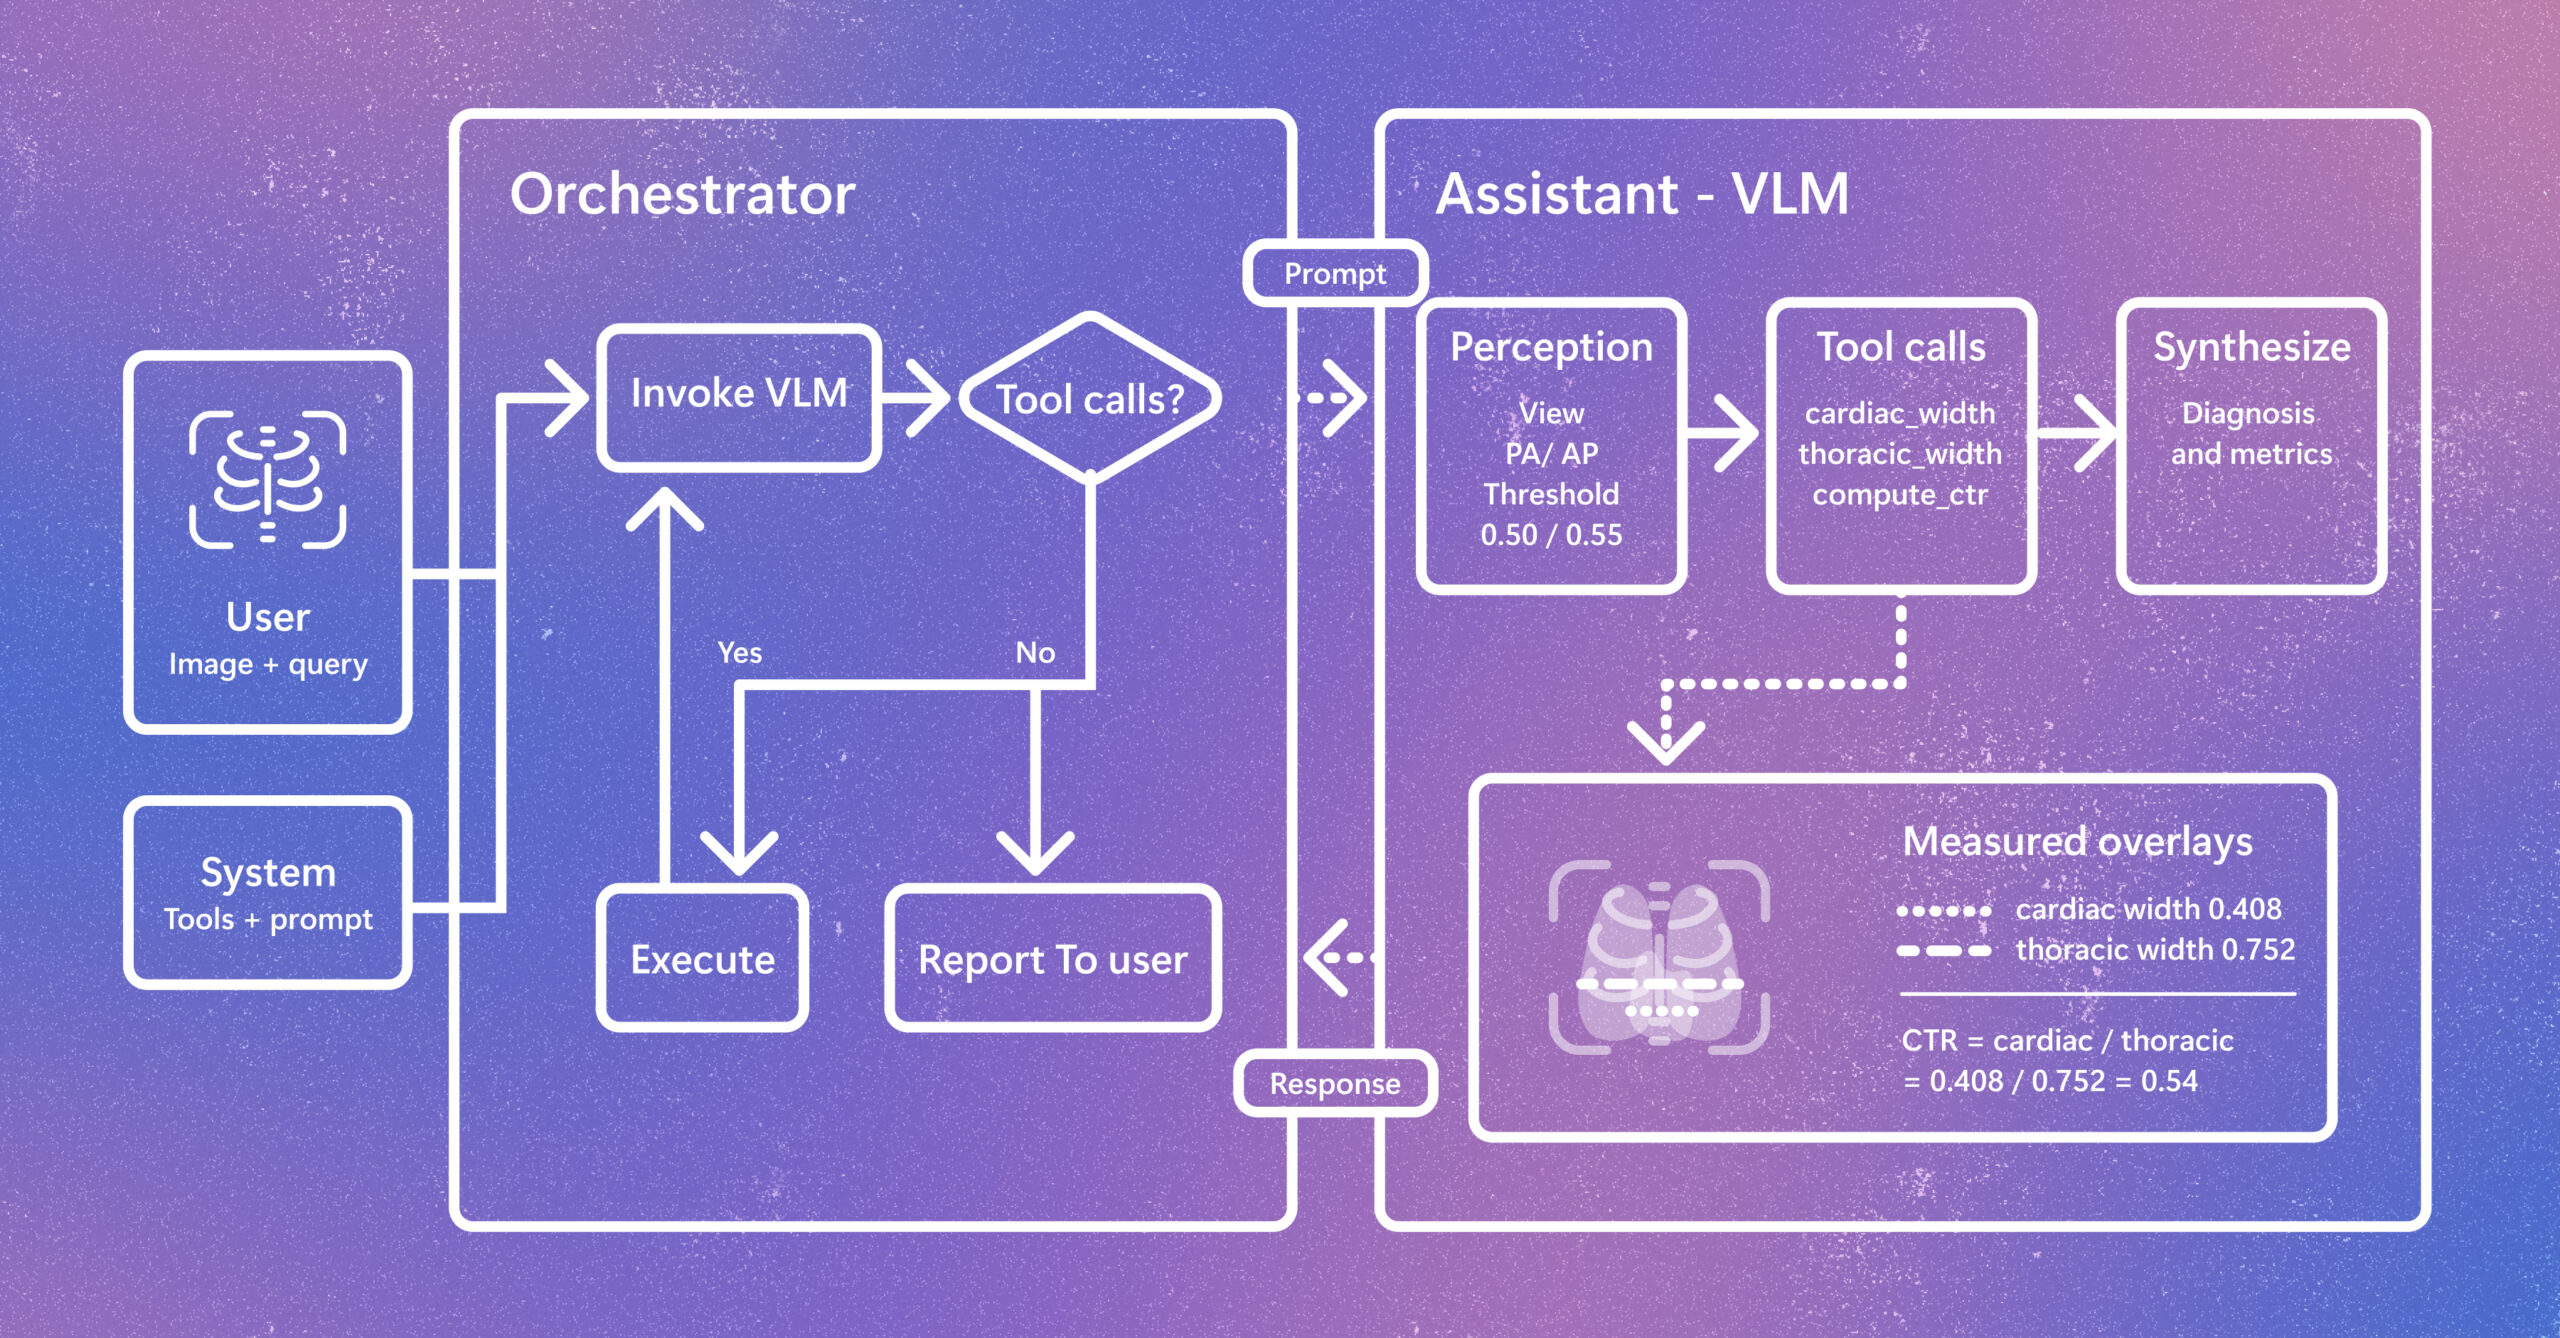
Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement

Radiology AI is evolving beyond report generation. CARE-X explores a unified approach that combines flexible reasoning, calibrated predictions, and measurement-based tools for chest X-ray interpretation. The post Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement appeared first on Microsoft Research.

We use cookies to run the site and, with your consent, for analytics and to show ads. See our Cookie Policy.