AERR-Nav: Adaptive Exploration-Recovery-Reminiscing Strategy for Zero-Shot Object Navigation
Jingzhi HuangJunkai HuangHaoyang YangHaoang LiYi Wang
Oct 2026
Machine LearningComputer VisionRobotics
Abstract
Zero-Shot Object Navigation (ZSON) in unknown multi-floor environments presents a significant challenge. Recent methods, mostly based on semantic value greedy waypoint selection, spatial topology-enhanced memory, and Multimodal Large Language Model (MLLM) as a decision-making framework, have led to improvements. However, these architectures struggle to balance exploration and exploitation for ZSON when encountering unseen environments, especially in multi-floor settings, such as robots getting stuck at narrow intersections, endlessly wandering, or failing to find stair entrances. To overcome these challenges, we propose AERR-Nav, a Zero-Shot Object Navigation framework that dynamically adjusts its state based on the robot's environment. Specifically, AERR-Nav has the following two key advantages: (1) An Adaptive Exploration-Recovery-Reminiscing Strategy, enables robots to dynamically transition between three states, facilitating specialized responses to diverse navigation scenarios. (2) An Adaptive Exploration State featuring Fast and Slow-Thinking modes helps robots better balance exploration, exploitation, and higher-level reasoning based on evolving environmental information. Extensive experiments on the HM3D and MP3D benchmarks demonstrate that our AERR-Nav achieves state-of-the-art performance among zero-shot methods. Comprehensive ablation studies further validate the efficacy of our proposed strategy and modules.

This paper investigates developing real-world perception for active agents, proposes Gibson Environment for this purpose, and showcases a set of perceptual tasks learned therein.
F. Xia, Amir Zamir, Zhi-Yang He et al.· 2018 IEEE/CVF Conference on...· 1,069 citations· ⚡112
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
Exploring how generative AI could make machine vision more accessible to businesses. The post GenEye in a Box: Making Machine Vision Something You Can Just Ask For appeared first on GPT-Lab.
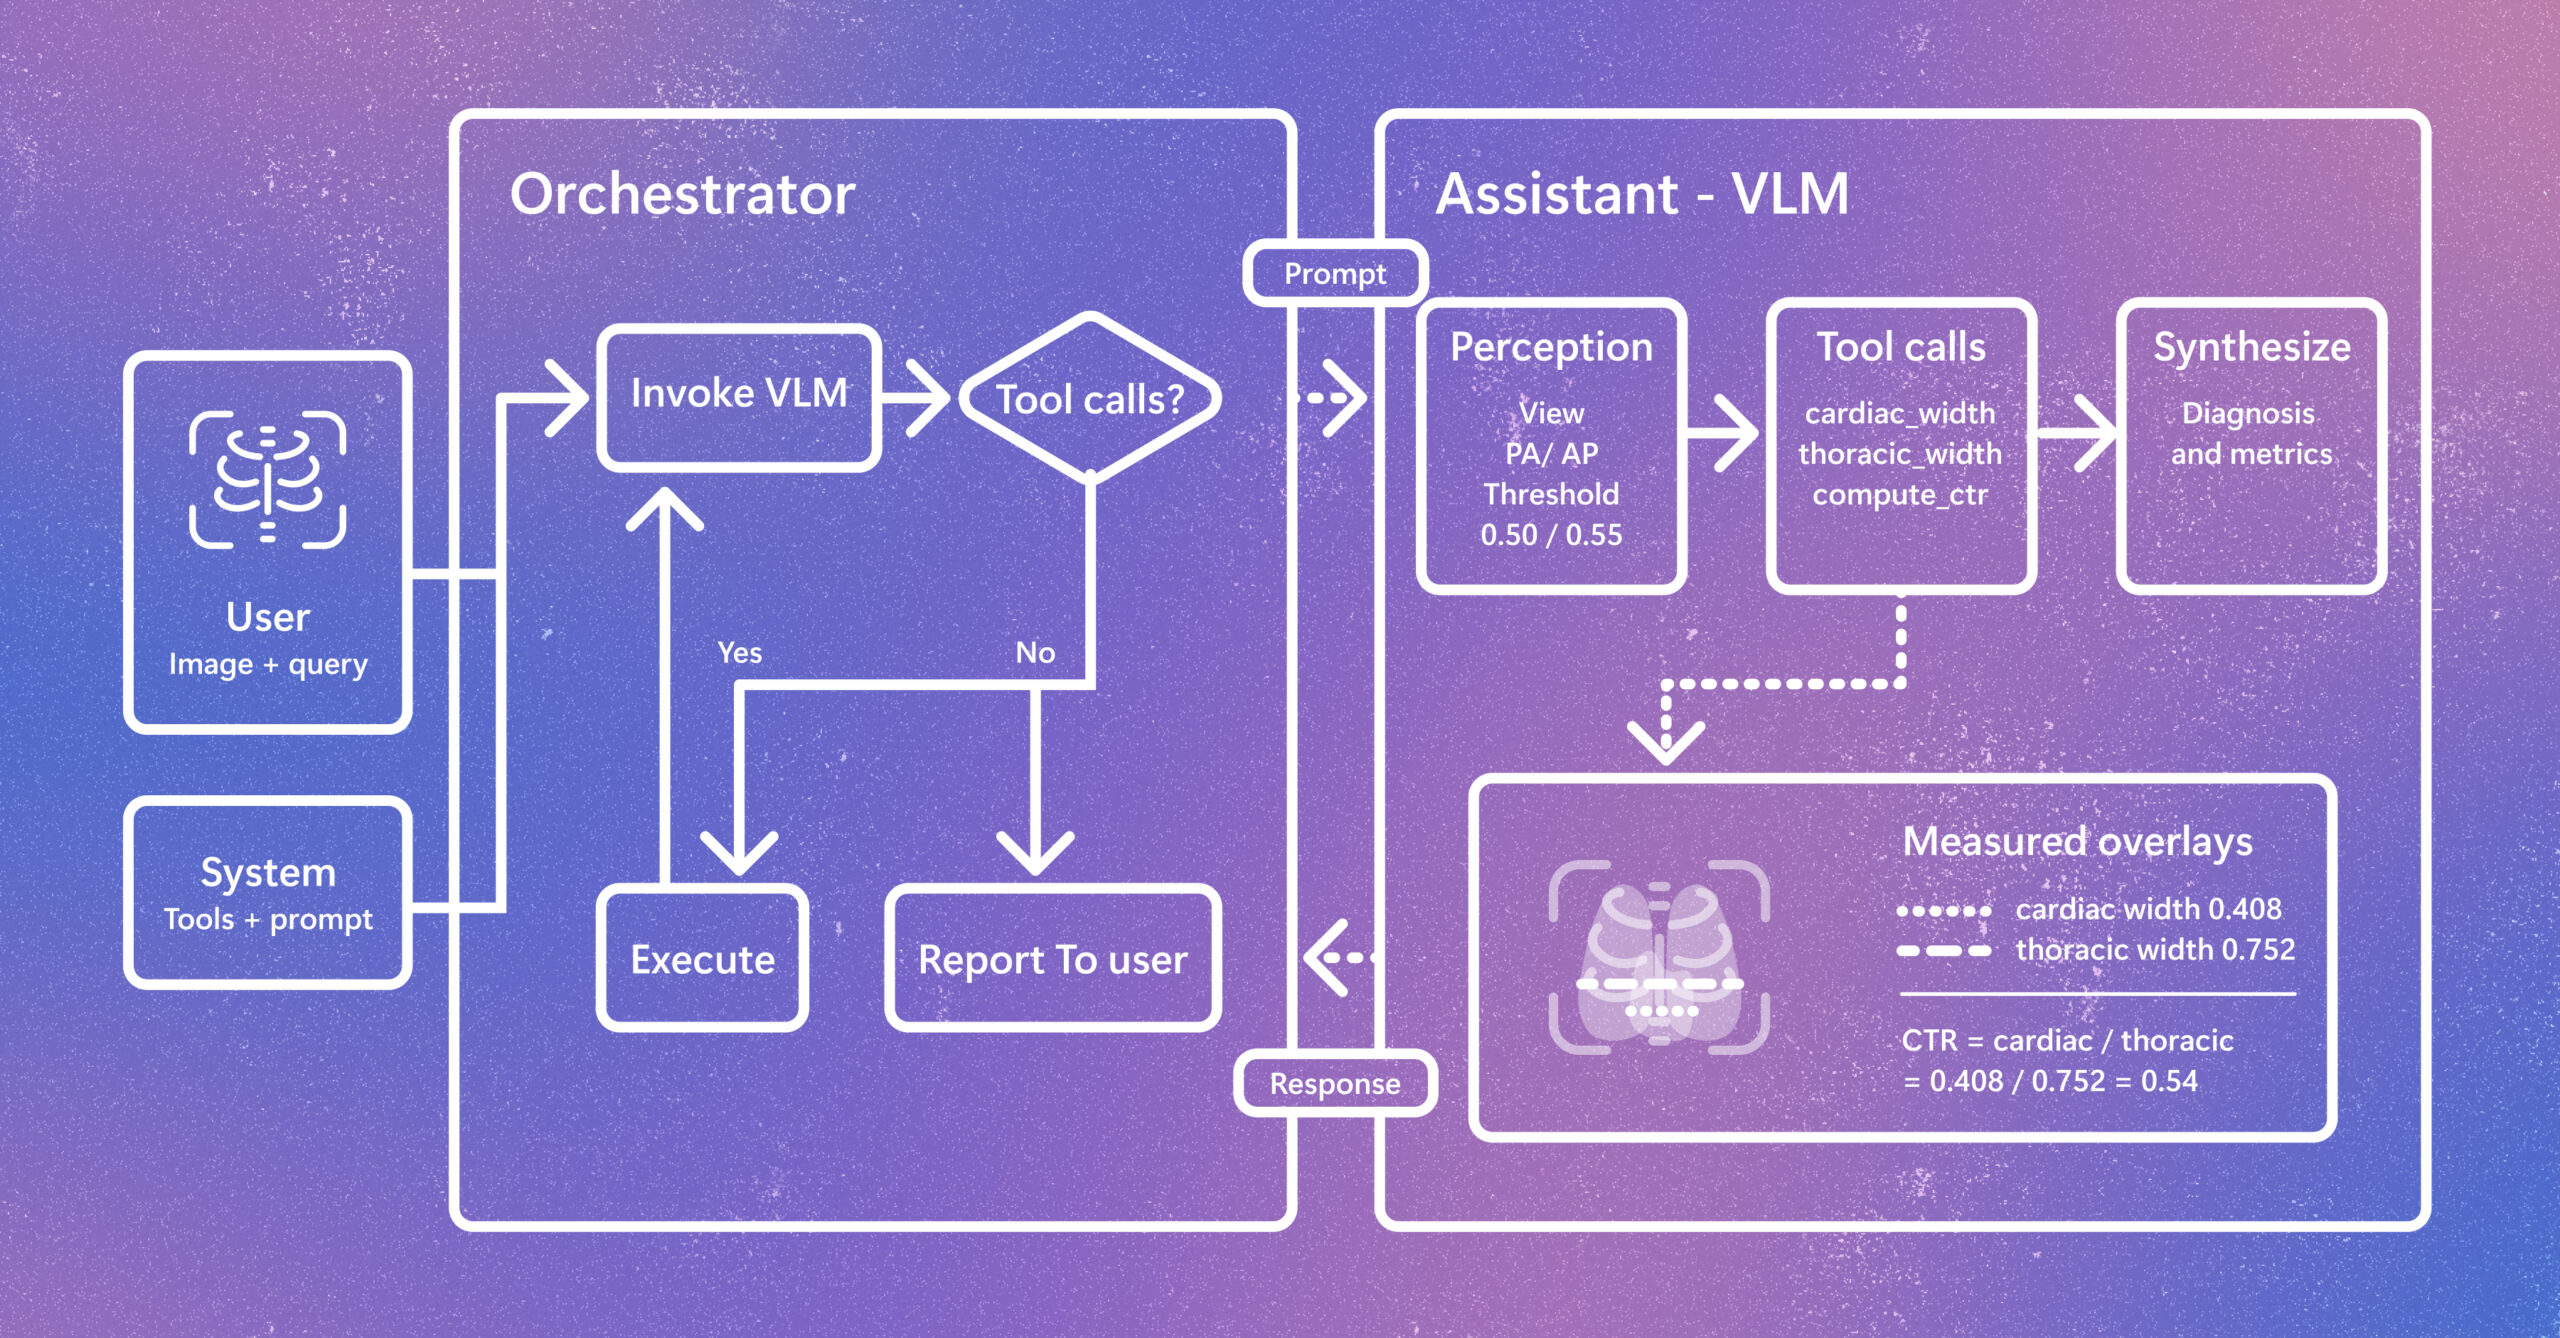
Radiology AI is evolving beyond report generation. CARE-X explores a unified approach that combines flexible reasoning, calibrated predictions, and measurement-based tools for chest X-ray interpretation. The post Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement appeared first on Microsoft Research.