Grid or Nodes? Probing Object Memory in World Models Under Partial Observability
Justin McMillenYasin Yilmaz
Oct 2026
Machine LearningComputer VisionRobotics
Abstract
A robot's world model must remember objects that leave the camera's view. FloWM, a learned world model, keeps them in a spatial grid of features that it moves with five built-in velocities. A node memory instead keeps each object's position and velocity as numbers. We compare them in FloWM's own block world, with an oracle-fed Kalman tracker as the node memory. How the grid is read changes its score: a single-cell probe finds 66% of out-of-view blocks, while FloWM's own probe 89%. FloWM also scores 8 points higher in view although no frame is shown, which we attribute to its write-back of its own predictions. Out of view, the tracker reaches FloWM's range in 14KB against 5.6MB, with no probe. On diagonal motion, outside its five velocities, FloWM finds 11% of blocks even after fine-tuning, while the unchanged tracker keeps 93%. Faster blocks defeat both until one more allowed speed takes the tracker to 94%, where FloWM's built-in shifts would need 25 copies of its grid. A learned node memory must still replace the oracles and handle velocity under noise, long gaps, and the bounce.

This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
It is proved that any global minimizer of the trajectory balance objective can define a policy that samples exactly from the target distribution, and empirically demonstrate the benefits of the trajectories balance objective for GFlowNet convergence, diversity of generated samples, and robustness to long action sequenc...
Esmeralda S. Whitammer, Moksh Jain, Emmanuel Bengio et al.· Neural Information Processin...· 302 citations· ⚡60
Exploring how generative AI could make machine vision more accessible to businesses. The post GenEye in a Box: Making Machine Vision Something You Can Just Ask For appeared first on GPT-Lab.
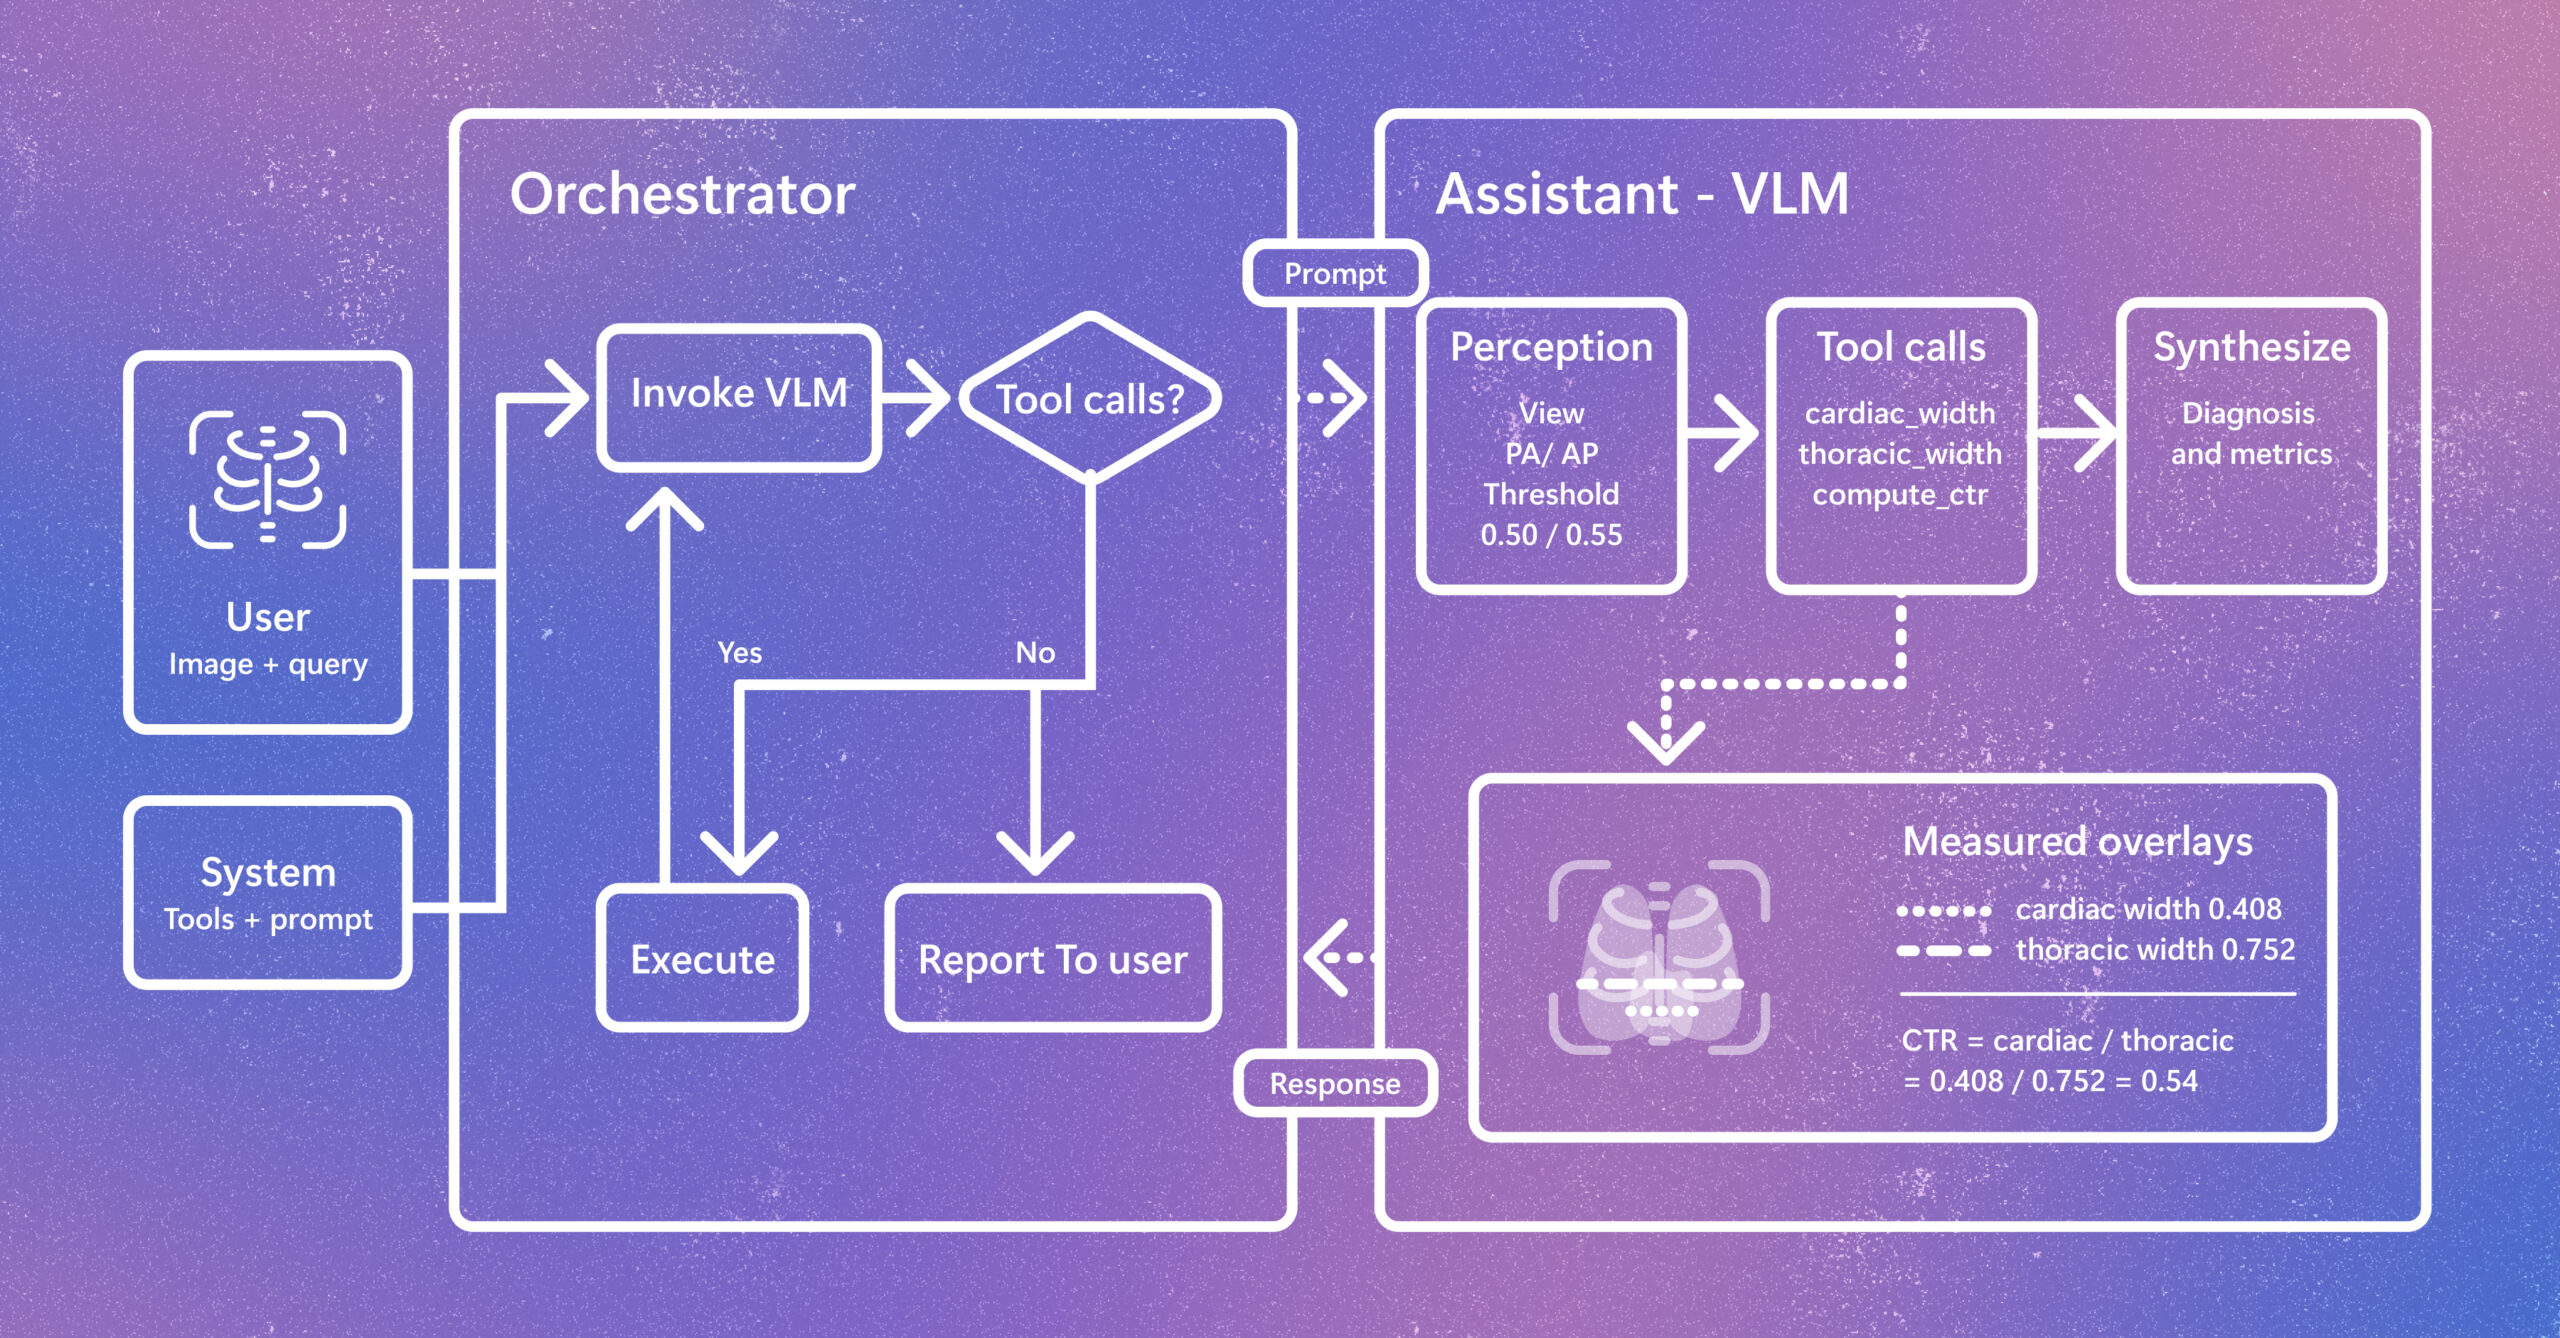
Radiology AI is evolving beyond report generation. CARE-X explores a unified approach that combines flexible reasoning, calibrated predictions, and measurement-based tools for chest X-ray interpretation. The post Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement appeared first on Microsoft Research.