Learning generalist policies capable of accomplishing a wide range of everyday tasks remains an open challenge in dexterous manipulation. In particular, collecting large-scale manipulation data via real-world teleoperation is expensive and difficult to scale. While learning in simulation provides a feasible alternative, designing multiple task-specific environments and rewards for training is similarly challenging. We propose Dex4D, a framework that instead leverages simulation for learning task-agnostic dexterous skills that can be flexibly recomposed to perform diverse real-world manipulation tasks. Specifically, Dex4D learns a domain-agnostic 3D point track conditioned policy capable of transforming a rigid object from a current pose to a target pose. We train this 'Anypose-to-Anypose' policy in simulation across thousands of objects with diverse pose configurations, covering a broad space of robot-object interactions that can be composed at test time. At deployment, this policy can be zero-shot transferred to real-world tasks without finetuning, simply by prompting it with desired object-centric point tracks extracted from generated videos. During execution, Dex4D uses online point tracking for closed-loop perception and control. Extensive experiments in simulation and on real robots show that our method enables zero-shot deployment for diverse dexterous manipulation tasks and yields consistent improvements over prior baselines. Furthermore, we demonstrate strong generalization to novel objects, scene layouts, backgrounds, and trajectories, highlighting the robustness and scalability of the proposed framework. Project page: https://dex4d.github.io/.

This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
Exploring how generative AI could make machine vision more accessible to businesses. The post GenEye in a Box: Making Machine Vision Something You Can Just Ask For appeared first on GPT-Lab.
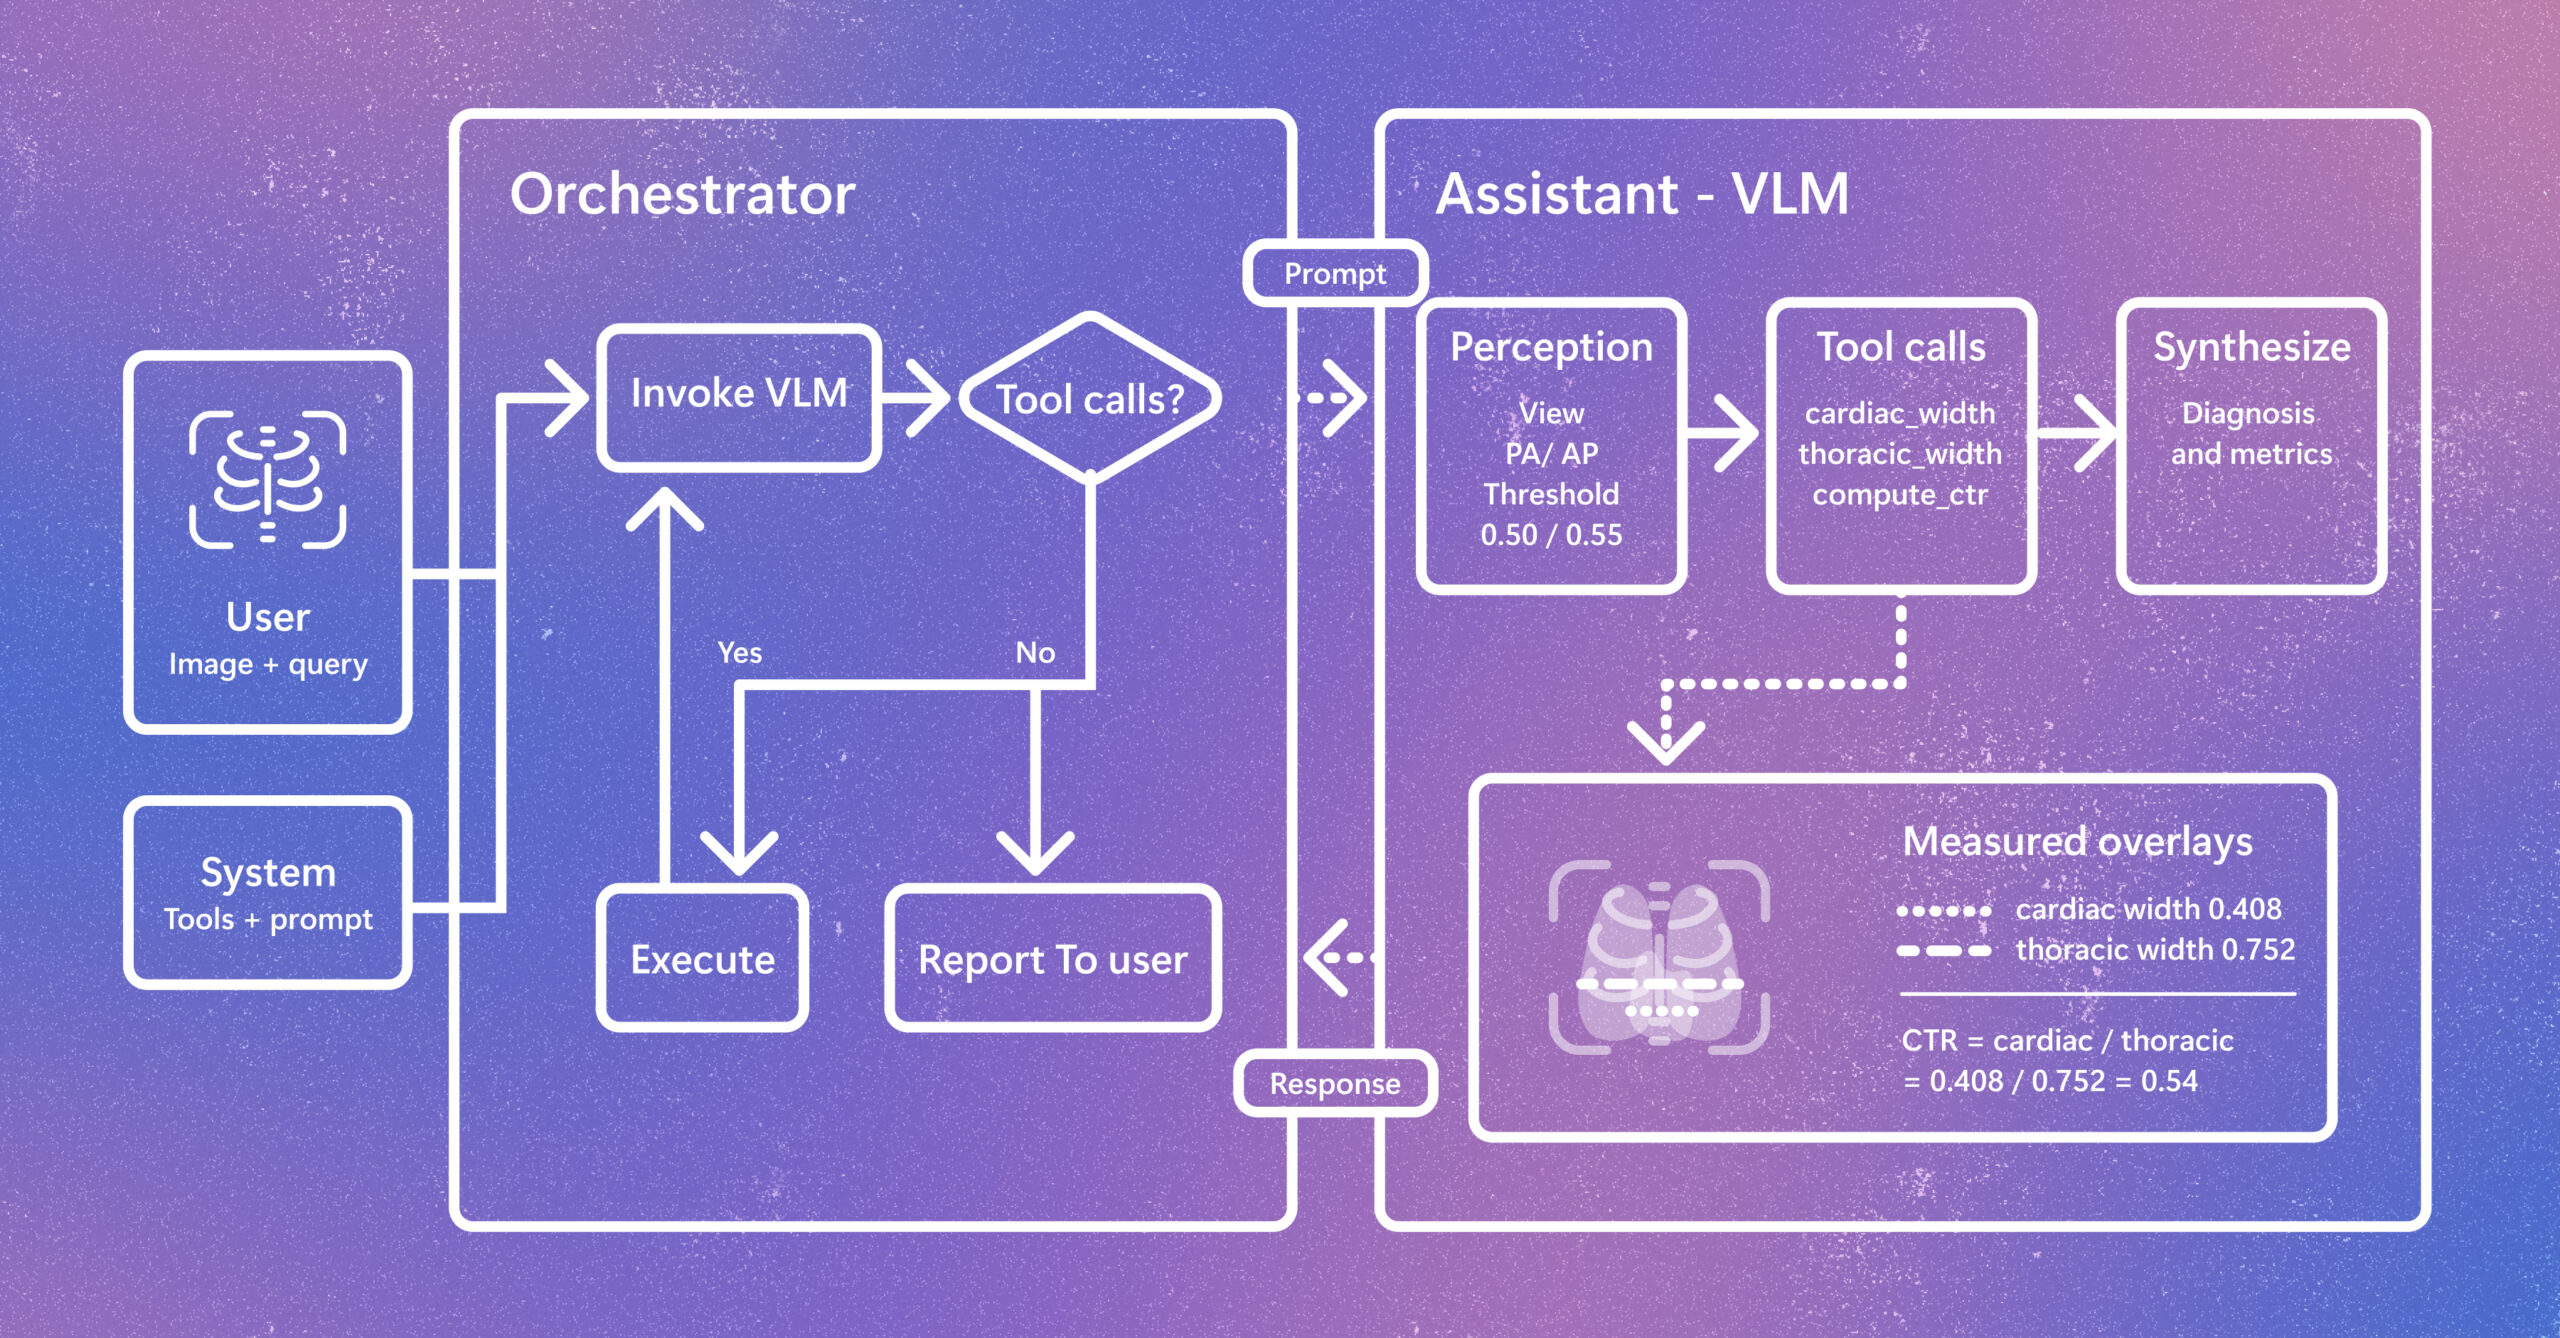
Radiology AI is evolving beyond report generation. CARE-X explores a unified approach that combines flexible reasoning, calibrated predictions, and measurement-based tools for chest X-ray interpretation. The post Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement appeared first on Microsoft Research.