Multi-robot cooperative visual SLAM schemes often suffer from narrow data transmission bandwidth, unsatisfactory runtime computation efficiency, poor anti-interference performance when dynamic objects exist, and unreliable alignment between multiple sub-maps. Against these practical engineering defects, this study puts forward a deep learning supported cooperative positioning and mapping scheme with online map merging capability. The whole system adopts a semi-distributed framework built with graph neural networks, which only transmits compressed scene descriptors rather than raw image data to lower transmission pressure and realize joint spatial constraint solving for robot groups. A self-learning ADR-Fusion module is further proposed to adjust fusion weights according to point cloud credibility and generate unified global semantic maps. Tests deployed on the Gazebo simulation platform prove that the absolute trajectory error is reduced by 25% against the classic EKF collaborative algorithm under bandwidth restrictions, with a map matching pass rate reaching 96%. The proposed scheme effectively improves mapping precision, scene adaptability and running speed for multi-agent exploration tasks.
Agile methods continue to gain popularity. In particular, the Scrum method appears to be on the verge of becoming a de-facto standard in the industry, leading the so called Agile movement. While there are success stories and recommendations, there is little scientifically valid evidence of the challenges in the adoptio...
A. Marchenko, P. Abrahamsson· Agile Conference· 59 citations· ⚡11
A comprehensive taxonomy of the challenges faced when a medium-scale organization decided to adopt software platforms is provided, namely: business challenges, organizational challenges, technical challenges, and people challenges.
Yaser Ghanam, F. Maurer, P. Abrahamsson· Information and Software Tec...· 41 citations· ⚡3
It is shown that high article processing charges are not sufficiently justified by the publishers, which often lack transparency and may prevent authors from adopting OA.
D. Graziotin, Xiaofeng Wang, P. Abrahamsson· Scientometrics· 21 citations· ⚡1
MCGLPPI, a novel geometric representation learning framework that combines graph neural networks (GNNs) with the MARTINI molecular coarse-grained (CG) model to predict overall PPI properties accurately and efficiently, offers an effective and efficient solution for PPI overall property predictions.
Yang Yue, Shu Li, Yihua Cheng et al.· bioRxiv· 15 citations
PepPCBench enables a robust evaluation of PFNN-based methods and supports their continued development for peptide-protein structure prediction, and highlights the influence of peptide length, conformational flexibility, and training set similarity on prediction accuracy.
Si-Long Zhai, Huifeng Zhao, Ji-Ke Wang et al.· Journal of Chemical Informat...· 13 citations· ⚡1
Abstract Predicting properties from coordinate–category data—sets of vectors paired with categorical information—is fundamental to computational science, manifesting in materials science as predicting formation energies or elastic moduli from crystal structures. While large language models (LLMs) have increasingly been...
Nawaf Alampara, Santiago Miret, Kevin Maik Jablonka· Nature Computational Science· 13 citations
Related blog posts
MIT News · Artificial Intelligence· news.mit.eduOct 13, 2026
Machine-learning networks can learn without detailed instructions from a designer. Those that do may offer insight into how the brain reorganizes itself during learning.
MIT News · Artificial Intelligence· news.mit.eduJul 15, 2026
Assistant Professor Pat Pataranutaporn describes a new interface that lets everyday users glimpse inside an AI's neural network before their chatbot ever says a word.
Microsoft Research Blog· microsoft.comJul 13, 2026
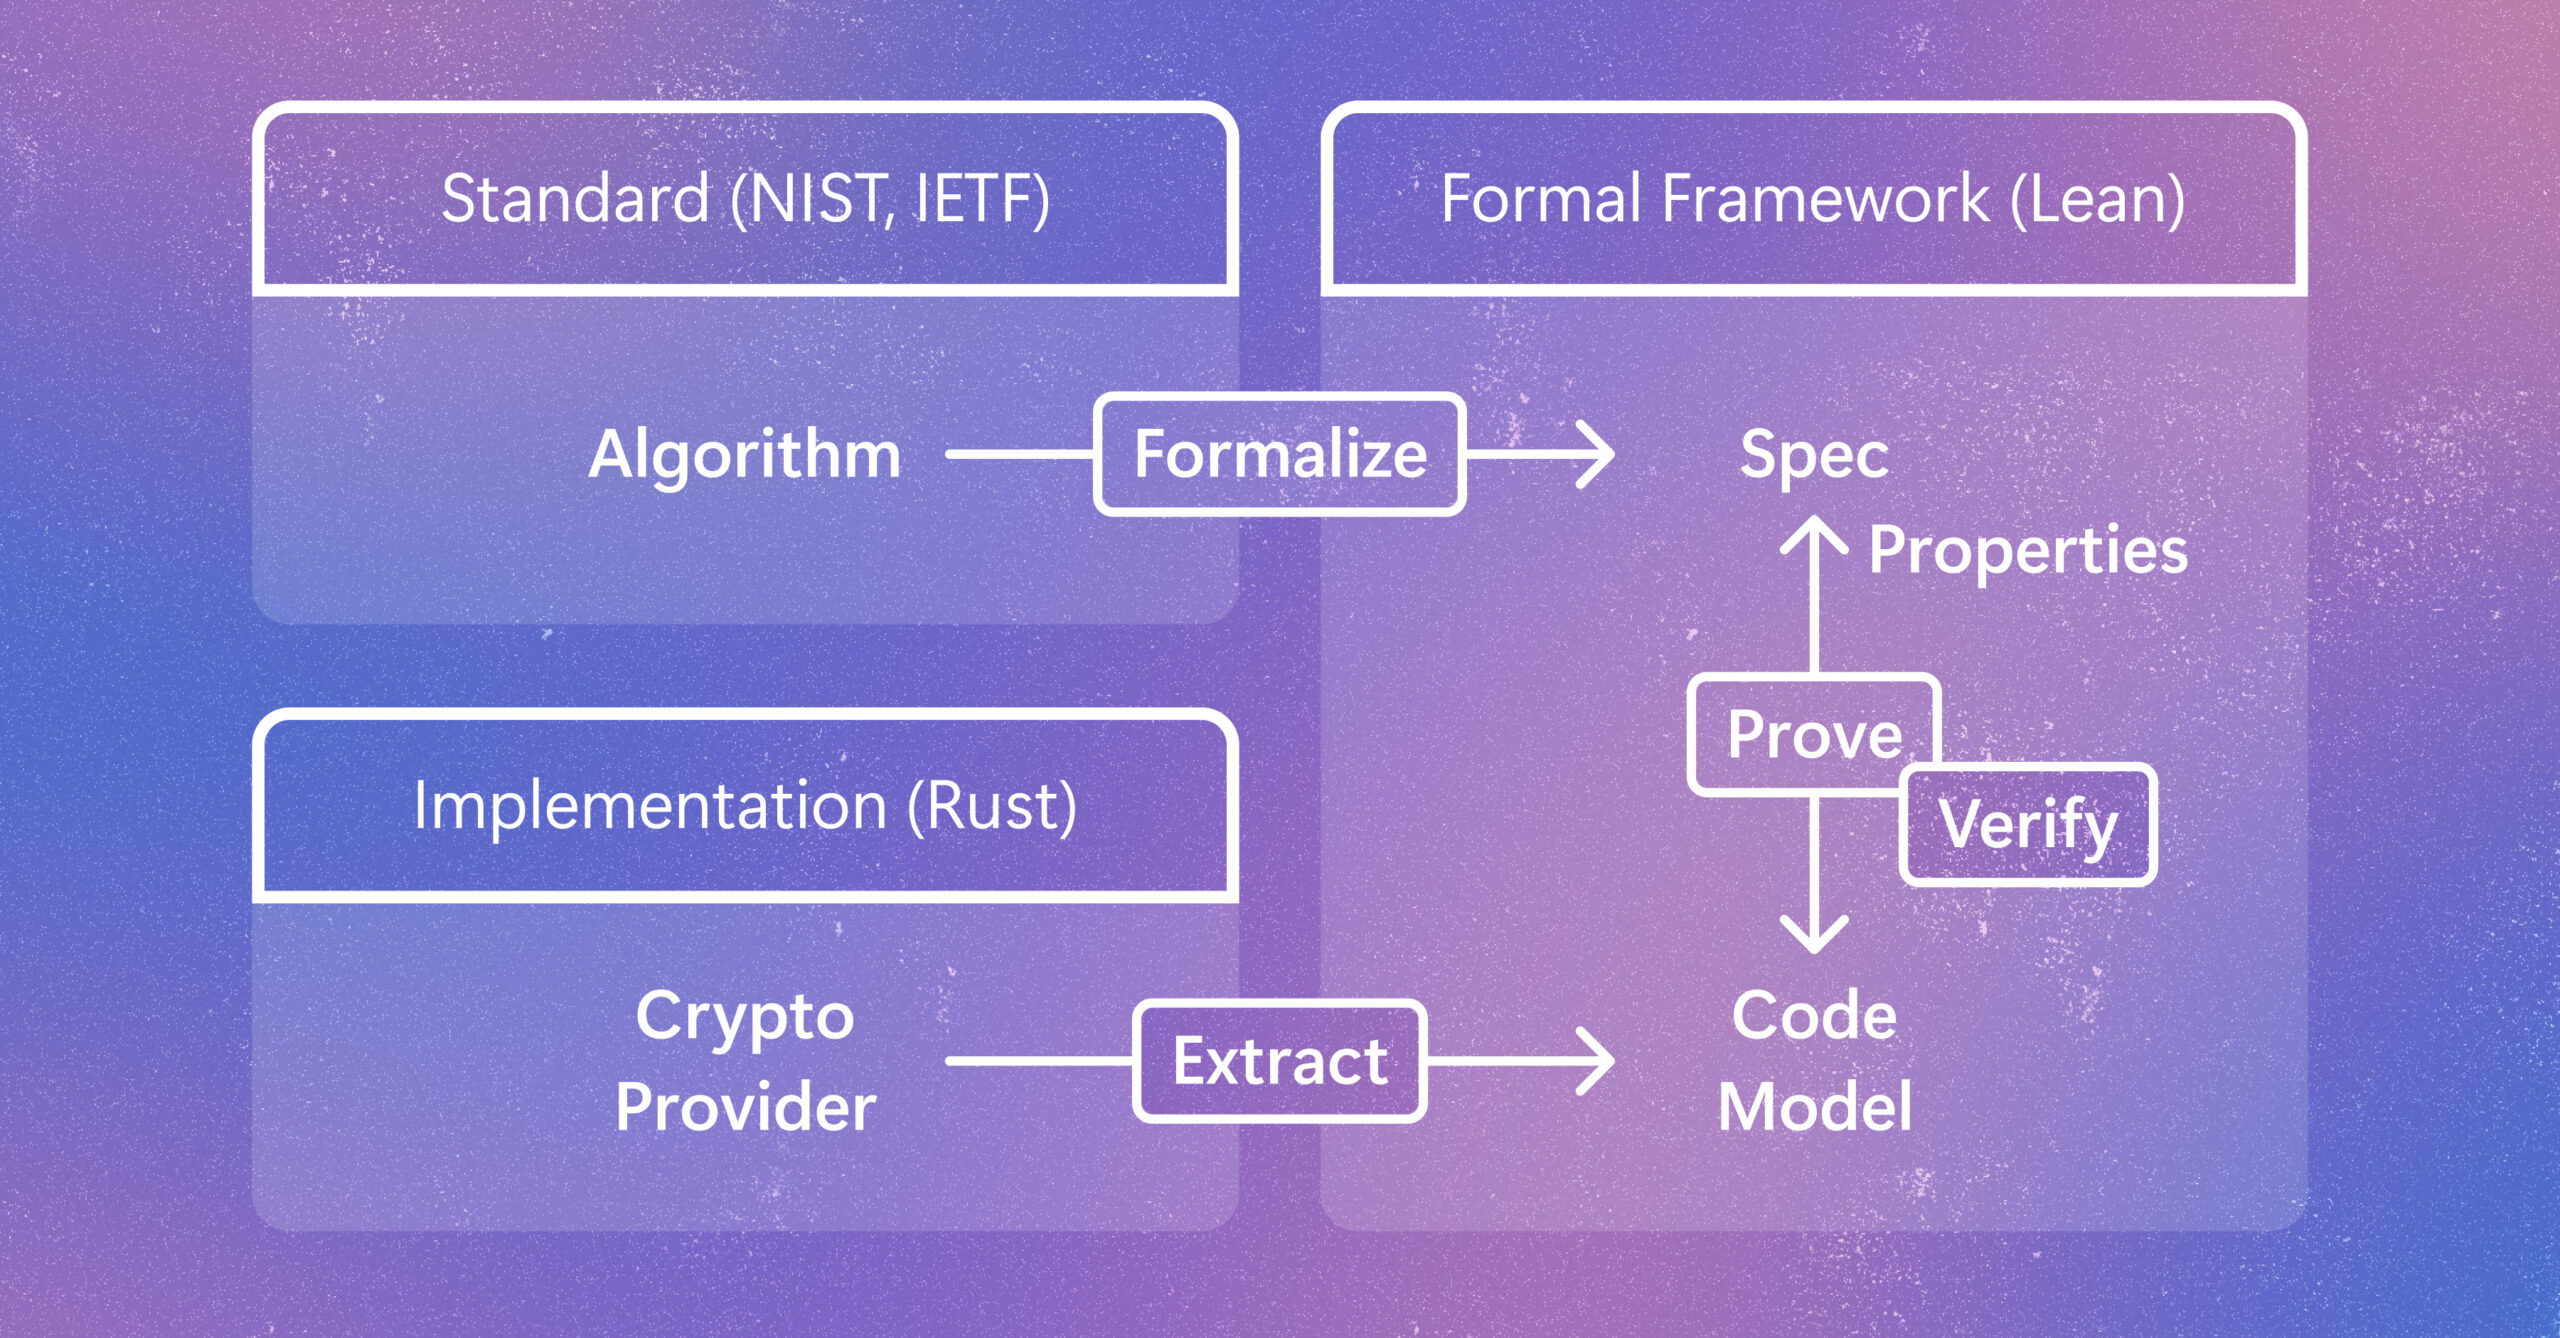
Cryptographic code supports vital protections in modern computing systems. Learn how a new method helps verify code as developers write it while preserving speed and adaptability as it gets implemented and evolves. The post Verifying Rust cryptography in SymCrypt, from standards to code appeared first on Microsoft Research.
MIT News · Artificial Intelligence· news.mit.eduJul 6, 2026
PhD student Rachel Sava, winner of the Envisioning the Future of Computing Prize, explores transformative improvements and dystopian risks of neural technology.
We use cookies to run the site and, with your consent, for analytics and to show ads.
See our Cookie Policy.