Aerial vision-language navigation (VLN) agents built on large vision-language models are expensive to query. Executing a complete predicted action chunk before replanning amortizes this cost, reducing model inference from 195 to 42 ms per executed waypoint for our policy. It also moves the states at which the policy is queried away from expert demonstrations, which supervise neither recovery from these states nor termination at the learner's own arrival. On OpenFly test-seen, no-stop failures account for 47.78% of full-chunk behavior cloning (BC) outcomes. We present X-Fly, a staged training framework for full-chunk aerial VLN. Recovery DAgger labels learner-visited decision states with smooth chunks that reconnect to future expert segments and with STOP at the first in-region state. Flow-GRPO then jointly refines the chunked flow controller and a Bernoulli STOP policy from same-task closed-loop outcomes, supplemented by outcome-verified stopping supervision. With eight controls per decision, X-Fly reaches 74.18% SR on test-seen and 51.73% on test-unseen, compared with 16.45% and 18.43% for full-chunk BC and 32.04% and 29.46% for DreamFly.
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
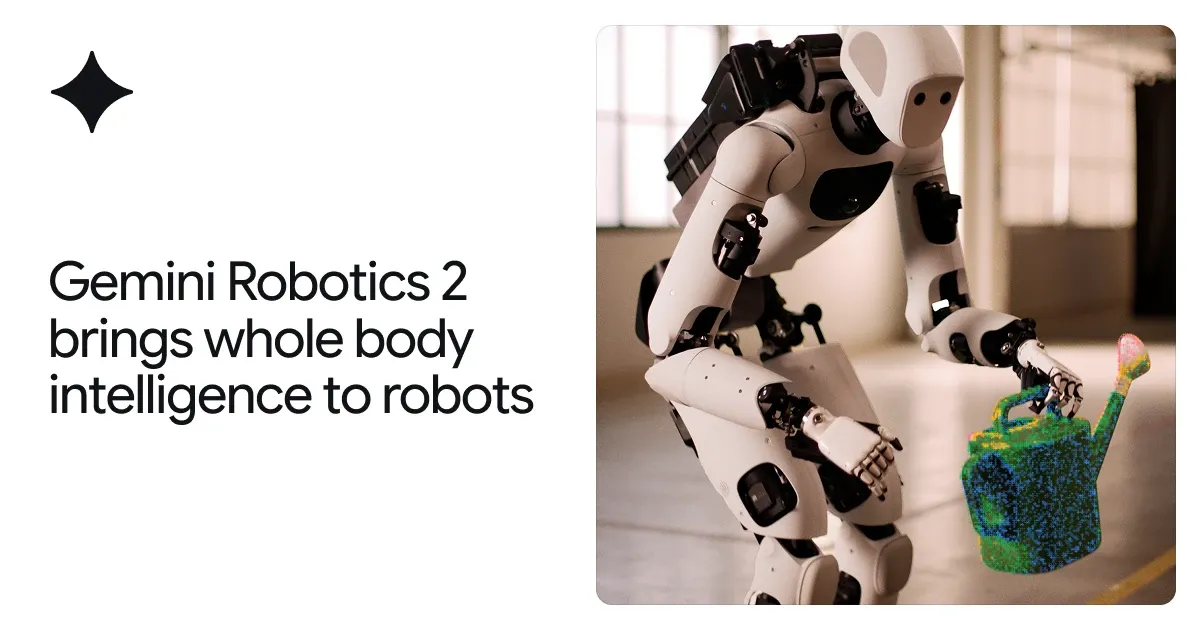
From feet to fingertips — we are teaching robots intelligent whole-body control, fine dexterity, and teamwork to complete a broad range of complex tasks.
Known for his clear and elegant writing style, Bertsekas shaped fields from control and optimization to large-scale computation and artificial intelligence.
We use cookies to run the site and, with your consent, for analytics and to show ads.
See our Cookie Policy.