GPT-6-Astra demonstrates a level of competence in robotic manipulation and navigation that challenges the conventional paradigm of building specialized models for individual tasks and embodiments. In this report, we ask not only how capable GPT-6-Astra is, but what its capabilities imply for the field. First, we probe the limits of standalone GPT-6-Astra. We conduct a large-scale evaluation across 12 representative benchmarks spanning tabletop manipulation, humanoids, mobile platforms, and dexterous hands. Under a unified protocol that allows in-context learning (ICL) from training-set demonstrations and substantially increases the number of execution steps, GPT-6-Astra achieves unprecedented performance (Fig. 1). Future research may focus on improving 1) the generality of ICL 2) cost and execution time, 3) physical-state verification, 4) recovery from irreversible failures, and 5) long-horizon preservation of progress. Second, we study the agentic harness for embodied control. We identify that close-loop coordination between a high-level "System 2" reasoner (i.e., GPT-6-Astra) and a low-level "System 1" controller (e.g., {\pi}0.5) is costly but effective. Third, we examine GPT-6-Astra on real-world deployment. Our experiments on 8 robot configurations reveal substantial gaps: 1) robot demonstrations required for ICL are expensive to collect, and 2) it is implausible to trade longer execution for higher success rates with physical constraints. Fourth, we envision the next generation of embodied benchmarks. We develop a prototype that 1) derives tasks from real-world needs, 2) provides no in-domain demonstrations, and 3) judges agents on a world clock that keeps running while they deliberate. Taken together, our results suggest that GPT-6-Astra has largely crossed the threshold of embodied competence, but not yet that of practical embodied intelligence.

This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
It is proved that any global minimizer of the trajectory balance objective can define a policy that samples exactly from the target distribution, and empirically demonstrate the benefits of the trajectories balance objective for GFlowNet convergence, diversity of generated samples, and robustness to long action sequenc...
Esmeralda S. Whitammer, Moksh Jain, Emmanuel Bengio et al.· Neural Information Processin...· 302 citations· ⚡60
Exploring how generative AI could make machine vision more accessible to businesses. The post GenEye in a Box: Making Machine Vision Something You Can Just Ask For appeared first on GPT-Lab.
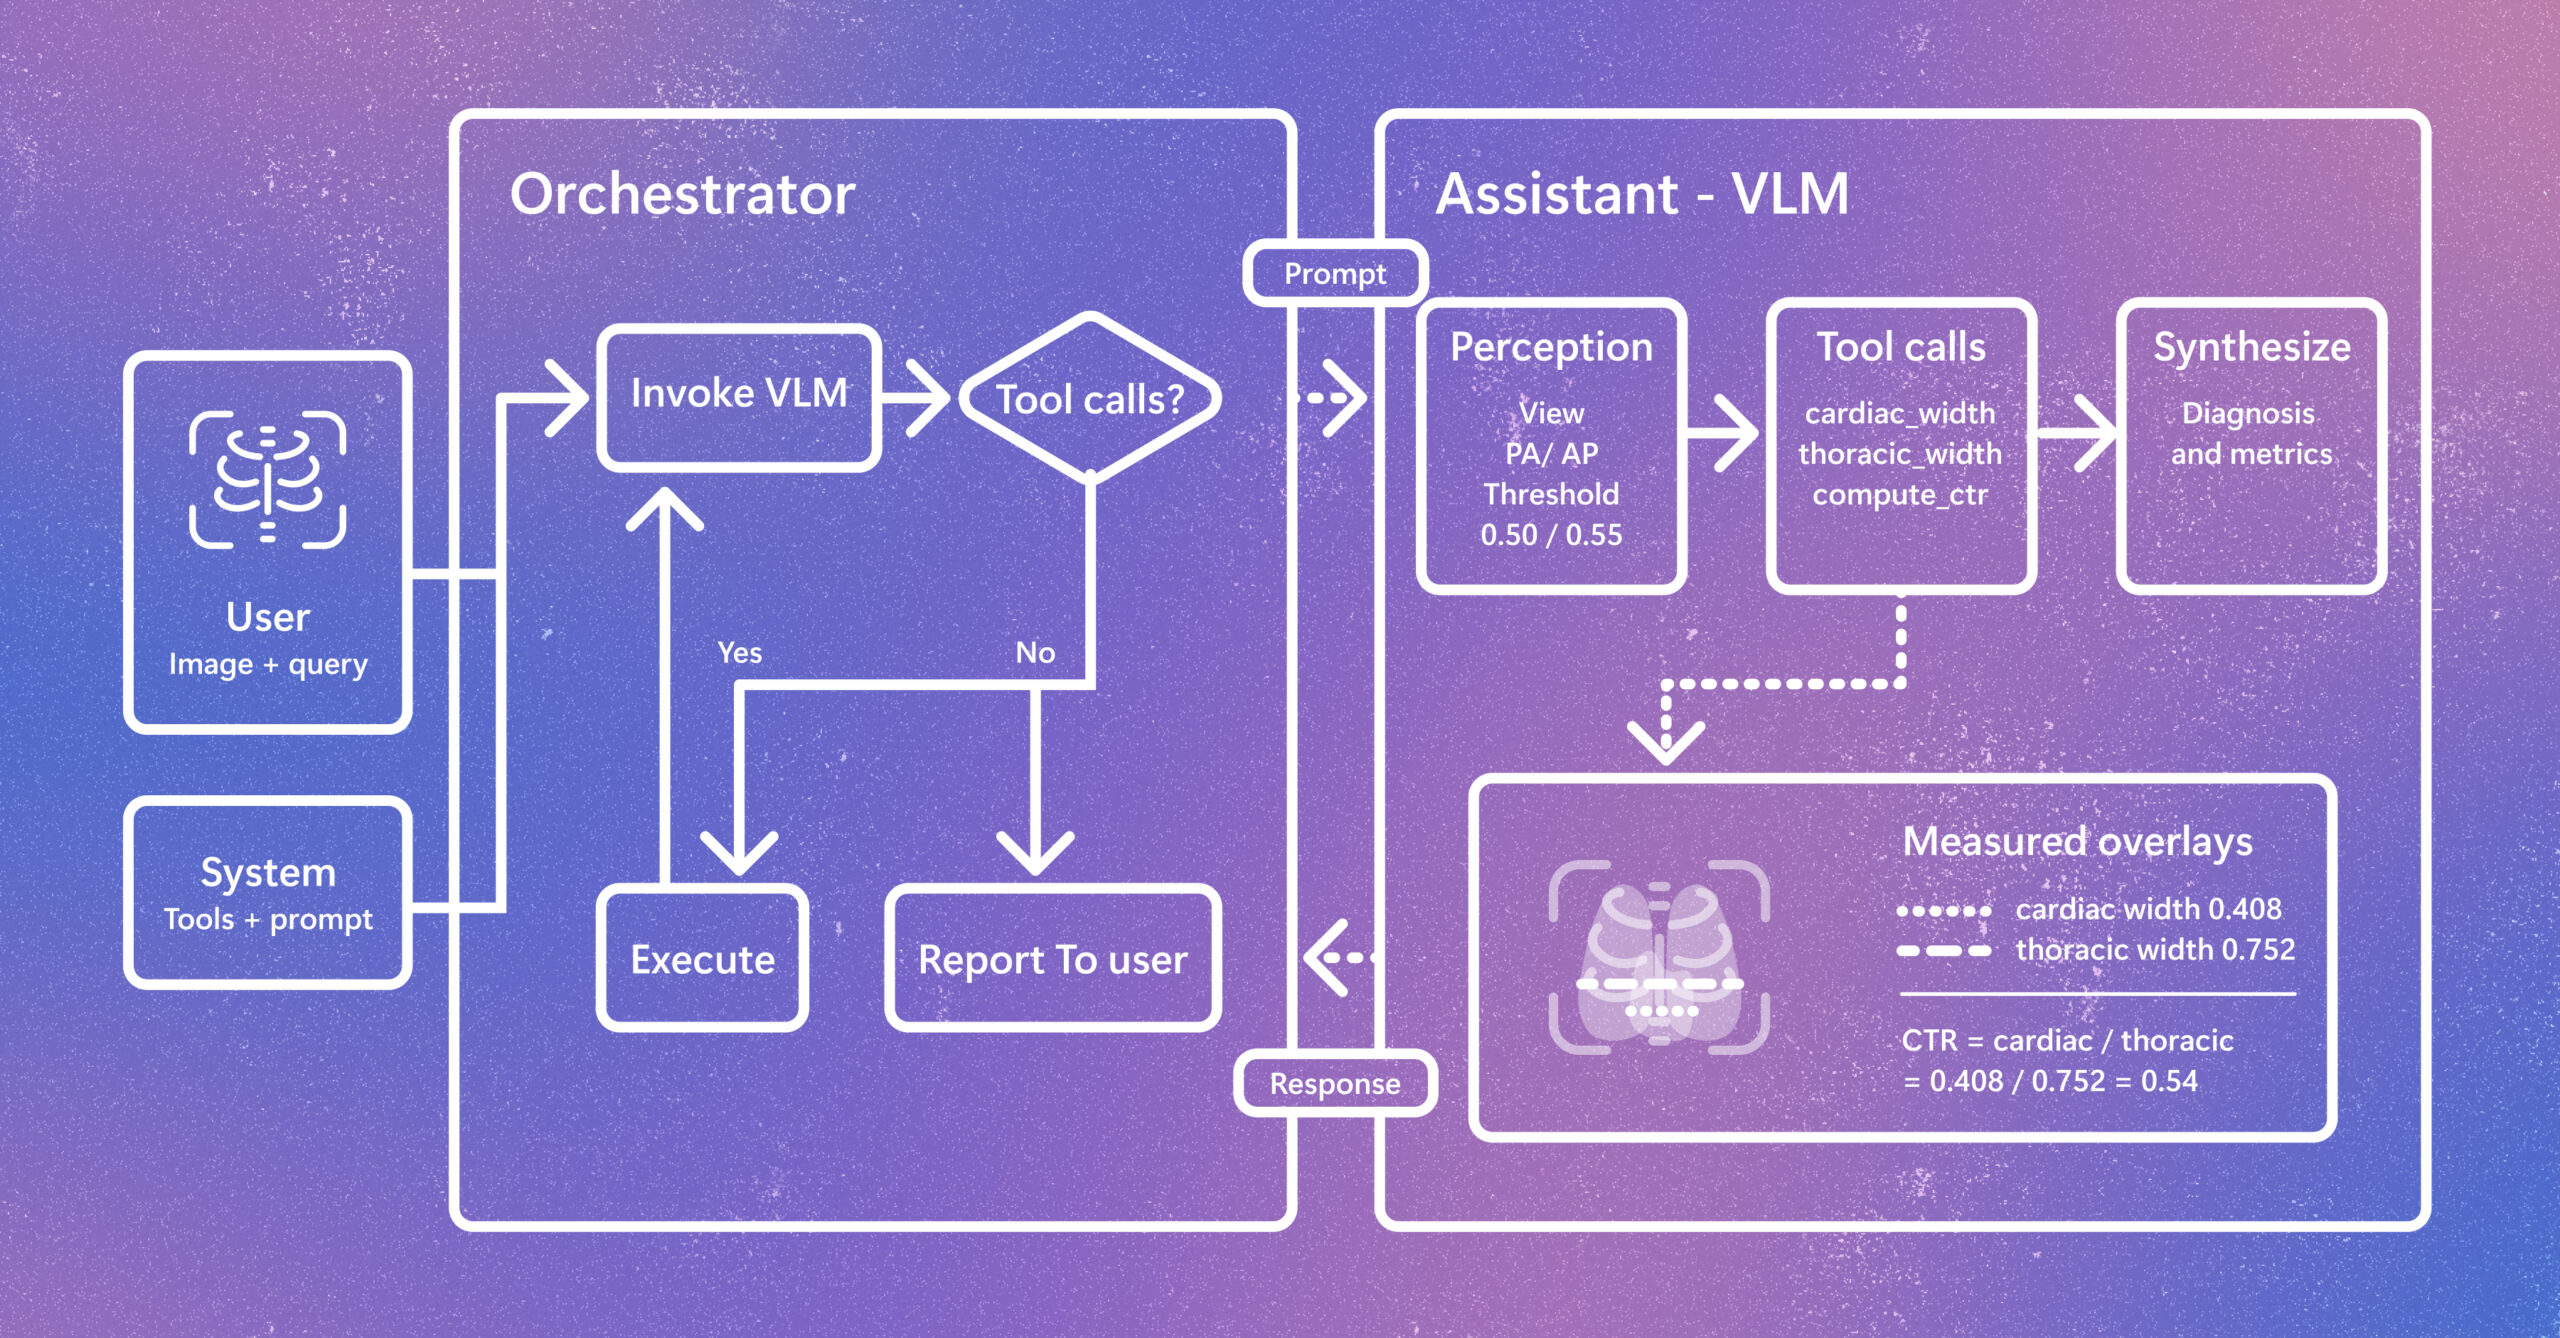
Radiology AI is evolving beyond report generation. CARE-X explores a unified approach that combines flexible reasoning, calibrated predictions, and measurement-based tools for chest X-ray interpretation. The post Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement appeared first on Microsoft Research.