Agriculture 4.0 robotic systems improve field efficiency yet remain too capital-intensive for the fragmented smallholdings that dominate global agriculture. Meanwhile, a growing number of retired low-speed electric-vehicle (LSEV) powertrains retain functional electromechanical value but are destructively recycled. This paper presents TS-MAMP (Telescopic-Sleeve Modular Agricultural Mobile Platform), a remanufactured robot built under 3R (reduce, reuse, recycle) circular-economy principles. Retired 48 V brushless-DC (BLDC) hub motors are paired via back-EMF matching, and lead-acid battery modules screened at 60%-80% state of health are actively balanced within a 100 mV inter-module voltage deviation. Together, these reused components reduce the powertrain-and-chassis BOM cost by approximately 60%, to below USD 450 (perception and weeding modules excluded). The truss chassis provides at least 200 kg static load, continuously adjustable track width from 1200 mm to 2000 mm, and no more than 5-minute module changeover. An NMS-free (non-maximum-suppression-free) YOLOv10n detector with consistent dual-assignment training and negative-sample learning achieves 80.87% mean average precision (mAP)@0.5 (58.41% mAP@0.5:0.95) on the Wanxi Crop-Weed dataset, and is deployed via FP16 TensorRT on a Jetson Nano, confirming on-device inference feasibility. TS-MAMP demonstrates that retired EV components, under modest screening, can be re-engineered into affordable, AI-enabled agricultural robots--opening a remanufacturing pathway for the smallholder fields that commercial automation leaves unserved.
GAOKAO-Bench is introduced, an intuitive benchmark that employs questions from the Chinese GAOKAO examination as test samples, including both subjective and objective questions that contribute a robust evaluation benchmark for future large language models and offers valuable insights into the advantages and limitations...
Xiaotian Zhang, Chun-yan Li, Yi Zong et al.· arXiv.org· 216 citations· ⚡17
An algorithm is proposed which leverages disentangled semantic factors to generate adversarial perturbation by altering controlled semantic attributes to fool the learner towards various "adversarial" targets.
Haonan Qiu, Chaowei Xiao, Lei Yang et al.· arXiv.org· 208 citations· ⚡17
This work proposes a HALO that directly maximizes the utility of generations instead of maximizing the log-likelihood of preferences, and suggests that the best loss depends on the inductive biases most appropriate for a given setting, an oft-overlooked consideration.
This work investigates the possibilities of using LLMs in a resume screening setting via a document retrieval framework that simulates job candidate selection and finds that the MTEs are biased, significantly favoring White-associated names in 85% of cases and female-associated names in only 11.1% of cases.
This work shows that orders of magnitude enhancement in performance could be obtained by a combination of hardware improvements and tight quantum-HPC integration and introduces high-performance architectures for quantum-probabilistic computing with custom-designed accelerators to tackle today's industry-scale classical...
Masoud Mohseni, Artur Scherer, K. Johnson et al.· arXiv.org· 121 citations· ⚡9
This paper presents a comprehensive overview of the Ultralytics YOLO family, emphasizing architectural evolution, benchmarking, deployment, and emerging directions from YOLOv5 through YOLO27, and examines detection, segmentation, depth, classification, pose, oriented detection, tracking, export, quantization, and deplo...
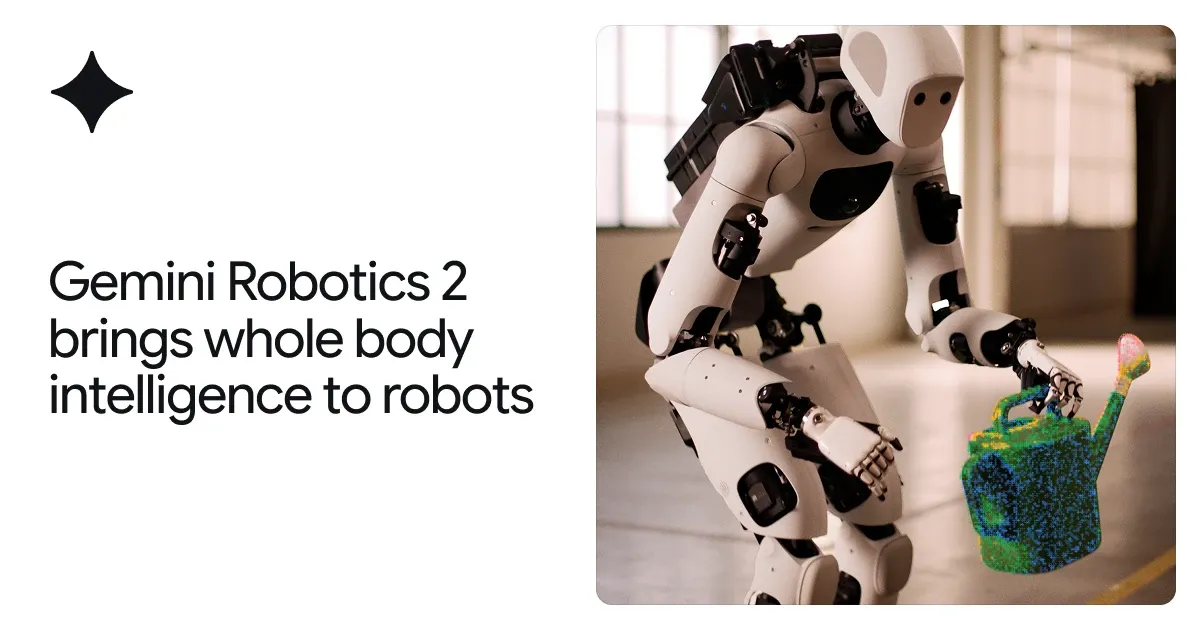
From feet to fingertips — we are teaching robots intelligent whole-body control, fine dexterity, and teamwork to complete a broad range of complex tasks.
MIT News · Artificial Intelligence· news.mit.eduOct 13, 2026
Machine-learning networks can learn without detailed instructions from a designer. Those that do may offer insight into how the brain reorganizes itself during learning.